


raygeo.ops.assembly.profile
ProfileRampSpec
Parameters for the profile ramp-entry assembler: it descends along the same loop the profile pass walks, so the tool enters the material gradually and the wall is never nicked by a vertical bore.
cut_direction
cut_direction: str
"cw" or "ccw".
kind
kind: str
"inner" or "outer".
ramp_angle
ramp_angle: float
Steepest descent along the loop (radians).
stock_to_leave
stock_to_leave: float
tolerance
tolerance: float
Boundary-following tolerance of the loop derivation.
tool_radius
tool_radius: float
wall_margin
wall_margin: float
z_end
z_end: float
z_start
z_start: float
for_tool()
for_tool(
    kind: str,
    tool_radius: float,
    ramp_angle: float,
    z_start: float,
    z_end: float,
) -> ProfileRampSpec
A ramp spec with the neutral defaults for the per-operation fields; set wall_margin,
stock_to_leave, cut_direction and tolerance on the result to match the ProfileSpec it leads
into.
| Parameter | Type | Description |
|---|---|---|
kind | str | "inner" or "outer". |
tool_radius | float | Tool radius in mm. |
ramp_angle | float | Steepest descent along the loop (radians). |
z_start | float | Height the ramp descends from. |
z_end | float | Depth the ramp descends to. |
| Returns | ProfileRampSpec |
ProfileSpec
Parameters for the adaptive-profile assembler.
cut_direction
cut_direction: str
"cw" or "ccw".
engagement_angle_threshold
engagement_angle_threshold: float
engagement_area_threshold
engagement_area_threshold: float
expansion_batch_size
expansion_batch_size: int
feed_reduction_factor
feed_reduction_factor: float
Factor (0–1) by which feed is reduced on over-engagement.
kind
kind: str
"inner" or "outer".
safe_z
safe_z: float
start_pos
start_pos: Optional[tuple[float, float]]
Optional override start (x, y).
step_length
step_length: float
step_over
step_over: float
stock_to_leave
stock_to_leave: float
target_z
target_z: float
tolerance
tolerance: float
tool_radius
tool_radius: float
trace_path
trace_path: Optional[str]
Optional path to write a binary trace file.
wall_margin
wall_margin: float
for_tool()
for_tool(
    kind: str,
    tool_radius: float,
    target_z: float,
    safe_z: float,
) -> ProfileSpec
A spec carrying the planner's canonical tuning for tool_radius: a radius-wide step-over, a
fifth-of-a-radius step length, the clearing planner's engagement gates (a 1.0 mm² area gate, and a
30-rad angle gate that never trips, so feed reduction is area-driven) and its 0.5 feed-reduction
factor. The per-operation fields keep their neutral defaults; set wall_margin, stock_to_leave,
cut_direction, tolerance, start_pos and trace_path on the result.
| Parameter | Type | Description |
|---|---|---|
kind | str | "inner" or "outer". |
tool_radius | float | Tool radius in mm. |
target_z | float | Cutting depth (Z). |
safe_z | float | Safe (rapid) Z height. |
| Returns | ProfileSpec |
Functions
profile_inner()
profile_inner(
    part: ops.part.Part,
    tool_radius: float = 3,
    step_over: float = 1.5,
    step_length: float = 0.6,
    target_z: float = -5,
    safe_z: float = 2,
    wall_margin: float = 0,
    stock_to_leave: float = 0,
    cut_feed_rate: int = 1000,
    cut_power: float = 0,
    start_pos: tuple[float, float] | None = None,
    cut_direction: str = 'ccw',
    engagement_area_threshold: float = 0,
    engagement_angle_threshold: float = 3.141592653589793,
    trace_path: str | None = None,
    plunge_feed_rate: int | None = None,
) -> ops.assembly.AssemblyResult
Profile the inner boundary of a pocket, around islands.
Walks a tool around the inset boundary (offset inward by tool radius) and around accessible islands, so that the tool clears the material along the pocket walls and around each island. Returns an AssemblyResult with the profiling move sequence.
| Parameter | Type | Description |
|---|---|---|
part | ops.part.Part | The part whose cleared field tracks accumulated workpiece state and whose geometry defines the pocket boundary and islands. |
tool_radius | float = 3 | Tool radius in mm. |
step_over | float = 1.5 | Radial step-over between passes (mm). |
step_length | float = 0.6 | Forward step length in mm. |
target_z | float = -5 | Cutting depth (Z). |
safe_z | float = 2 | Safe (rapid) Z height. |
wall_margin | float = 0 | Extra distance to keep from the wall (mm). |
stock_to_leave | float = 0 | Stock left on wall for rough pass (mm, default 0.0). |
cut_feed_rate | int = 1000 | Feed rate in mm/min. |
cut_power | float = 0 | Spindle power (0.0–1.0). |
start_pos | tuple[float, float] | None = None | Optional override start (x, y) (default: first boundary vertex). |
cut_direction | str = 'ccw' | "cw" or "ccw" (default "ccw"). |
engagement_area_threshold | float = 0 | Overengagement area threshold (mm², 0 = auto). |
engagement_angle_threshold | float = 3.141592653589793 | Overengagement angle threshold (rad, default π). |
trace_path | str | None = None | Optional path to write a binary trace file (default None). |
plunge_feed_rate | int | None = None | Vertical plunge feed in mm/min for the descent into material (default None: cut feed). |
| Returns | ops.assembly.AssemblyResult | An AssemblyResult with the profiling path. |
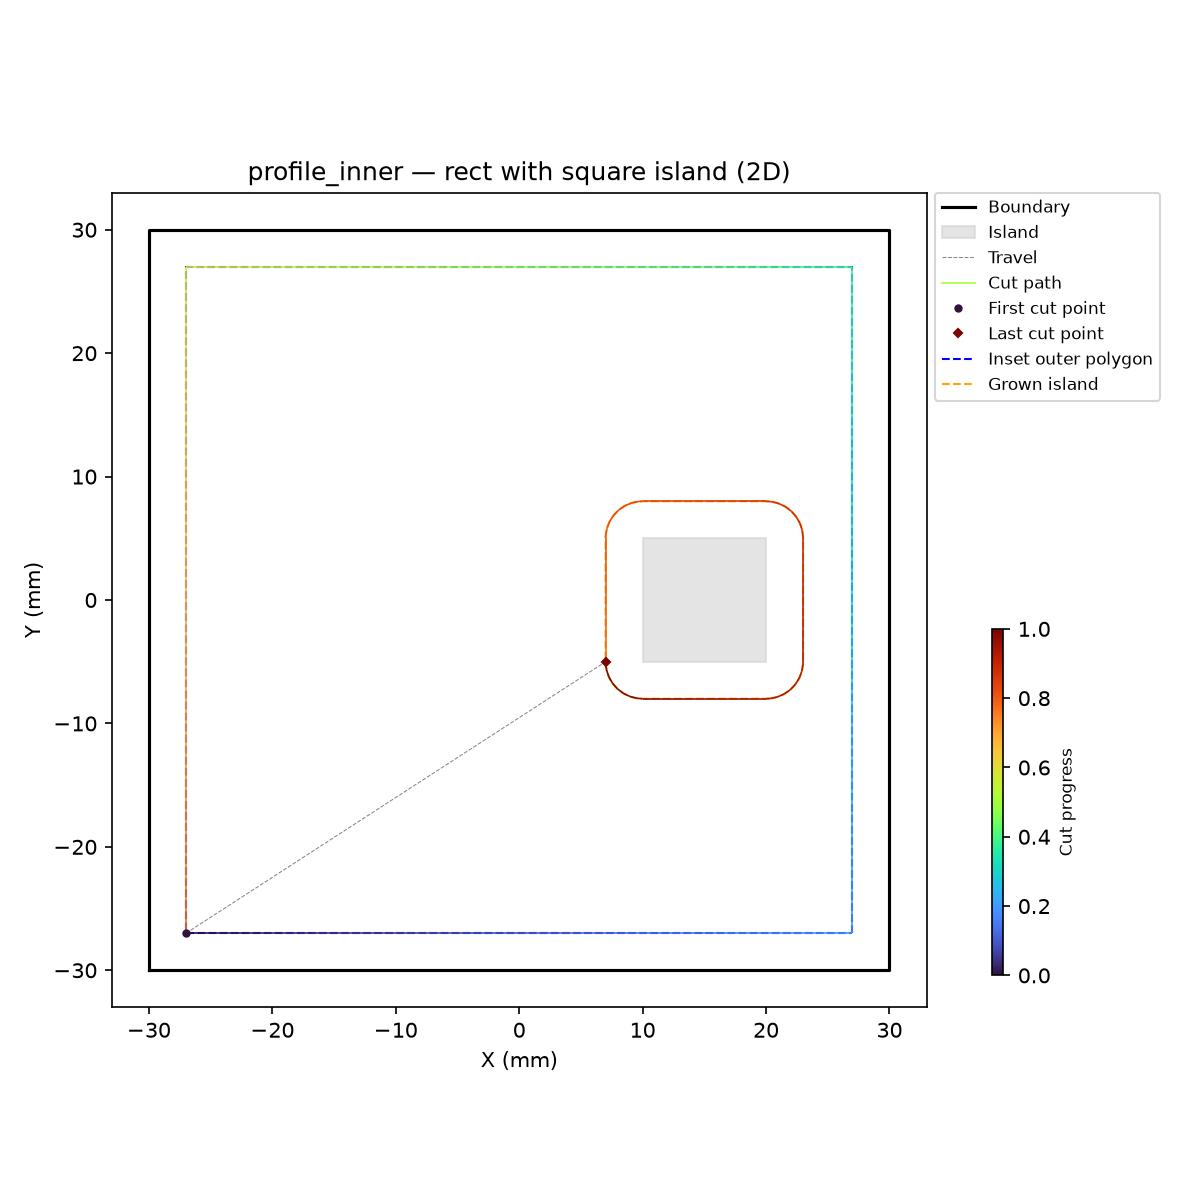
profile_inner on a square pocket with island — 2D: boundary, island, offset walks, cuts (turbo).
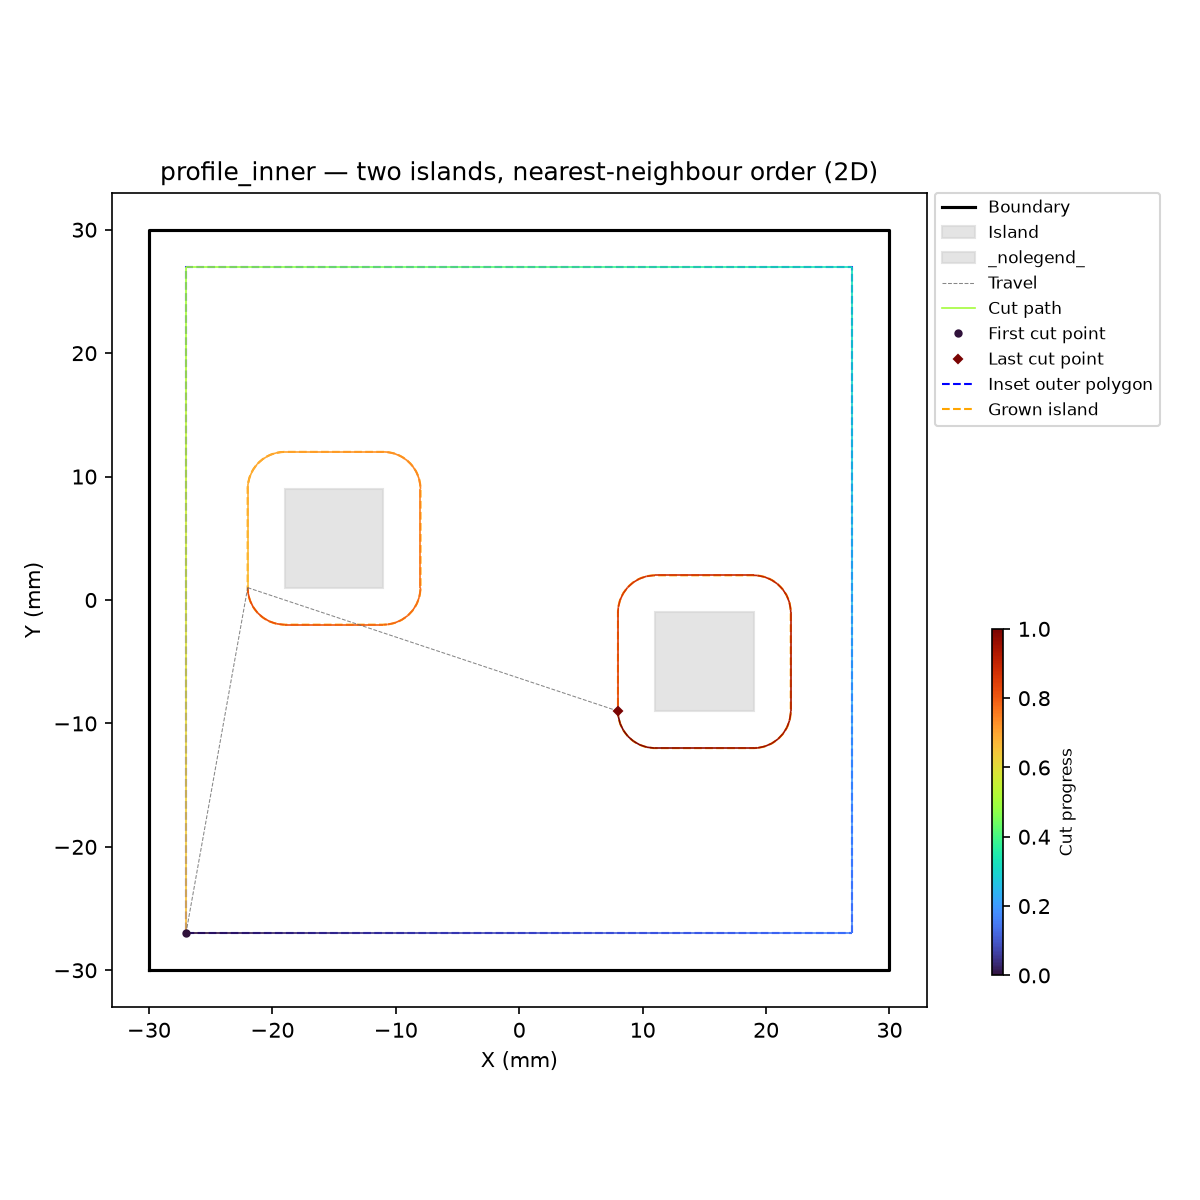
profile_inner with two accessible islands — nearest-neighbour order via turbo gradient.
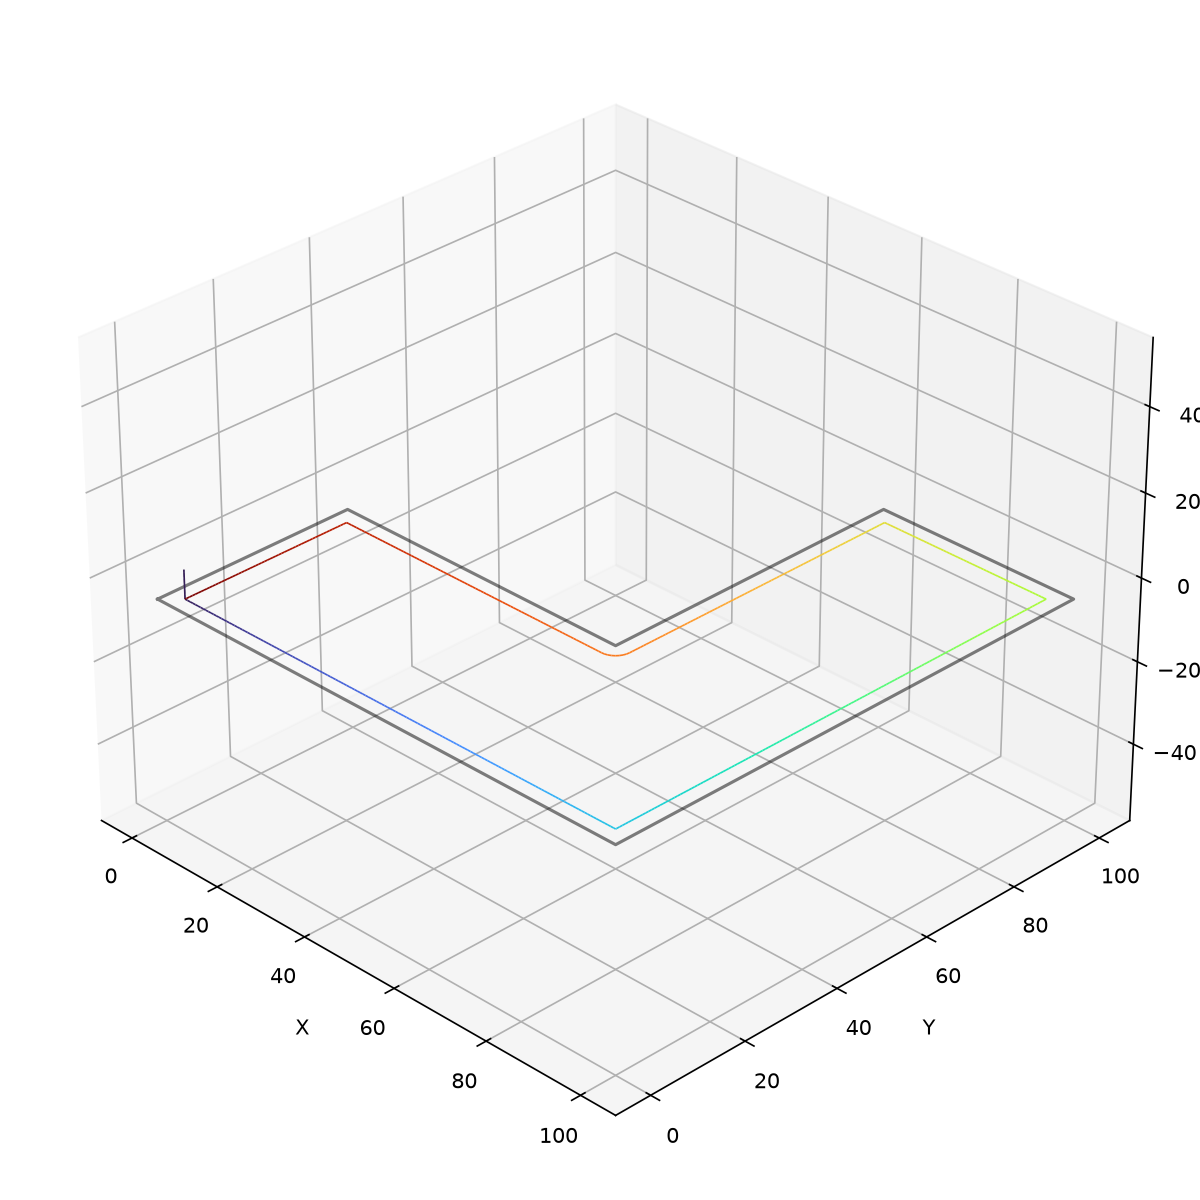
profile_inner on an L-shaped pocket with island — 3D: cut path at cut_z, rapids at safe_z.
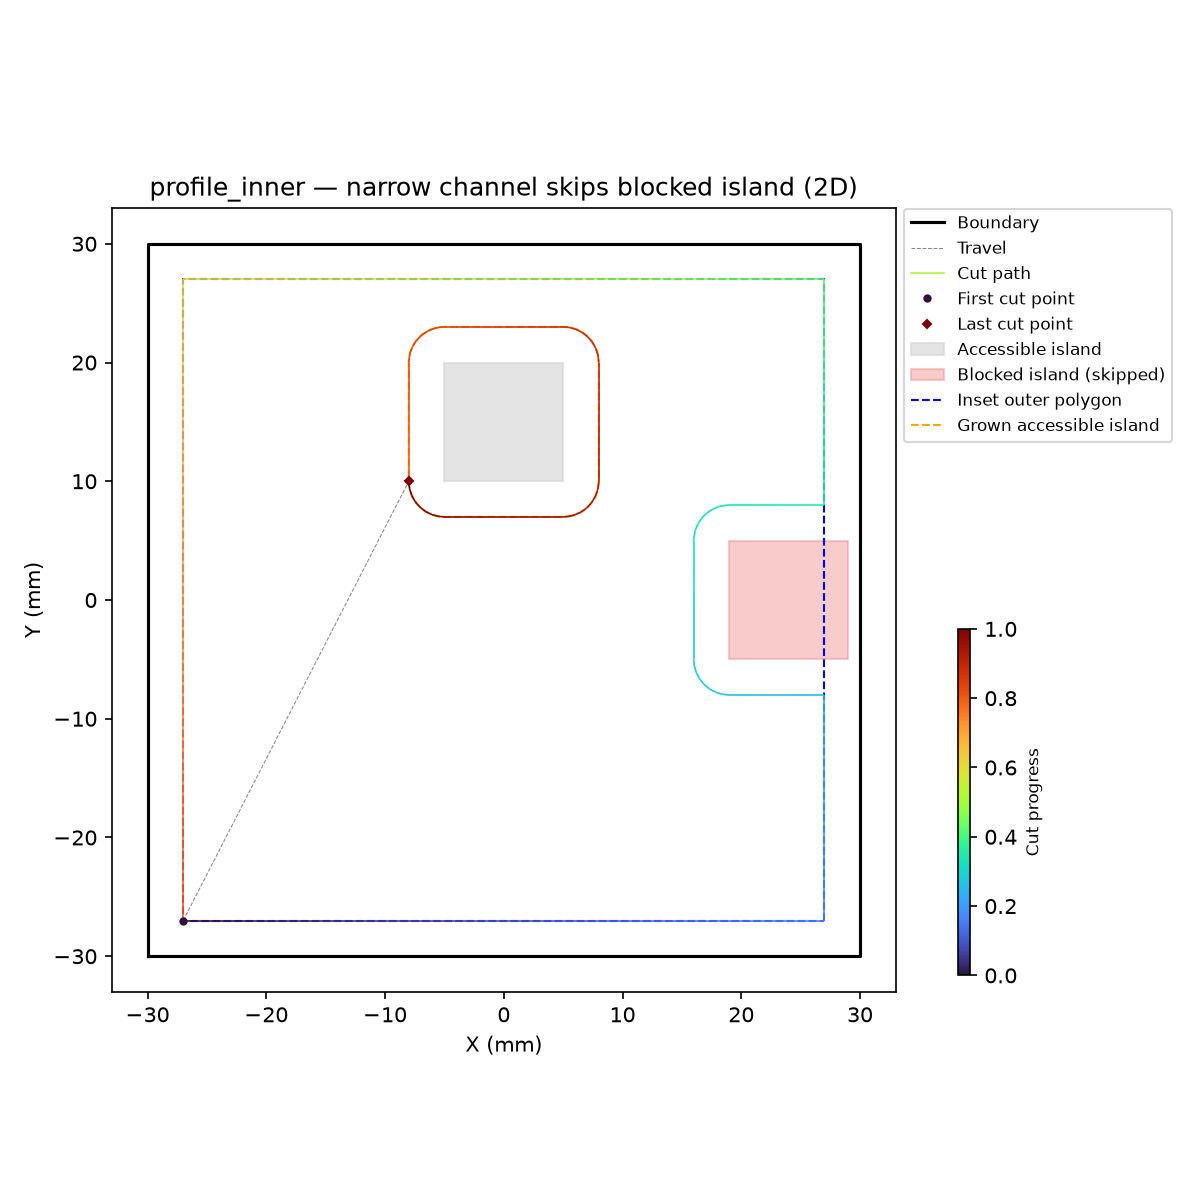
profile_inner skips an island when the channel between island and wall is too narrow.
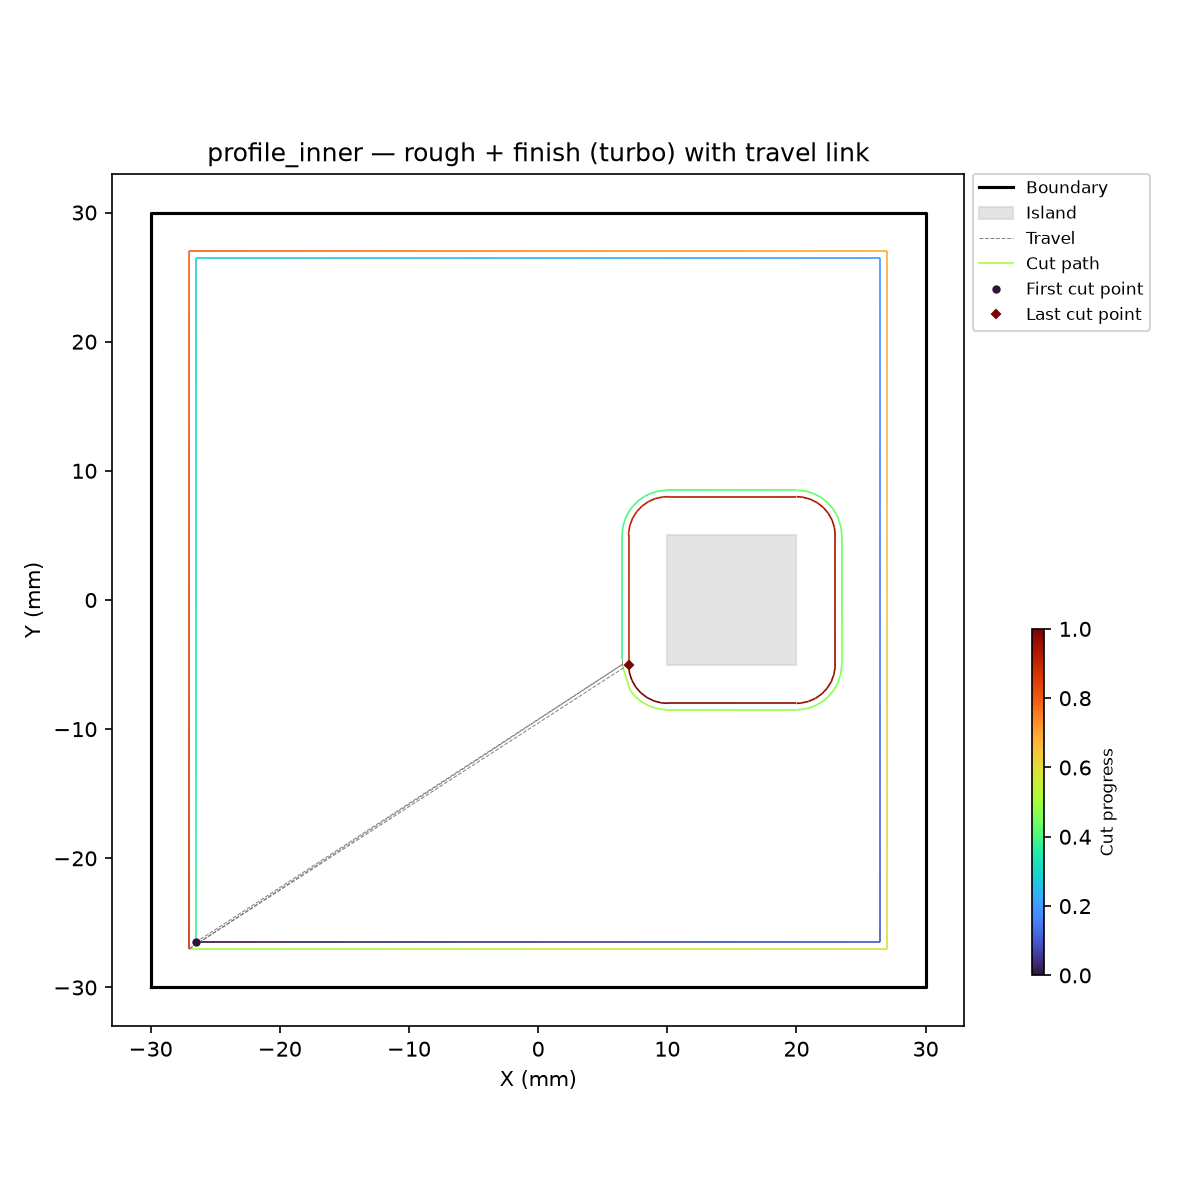
Two-pass inner profiling: rough (orange) + finish (red) on same ClearedArea.
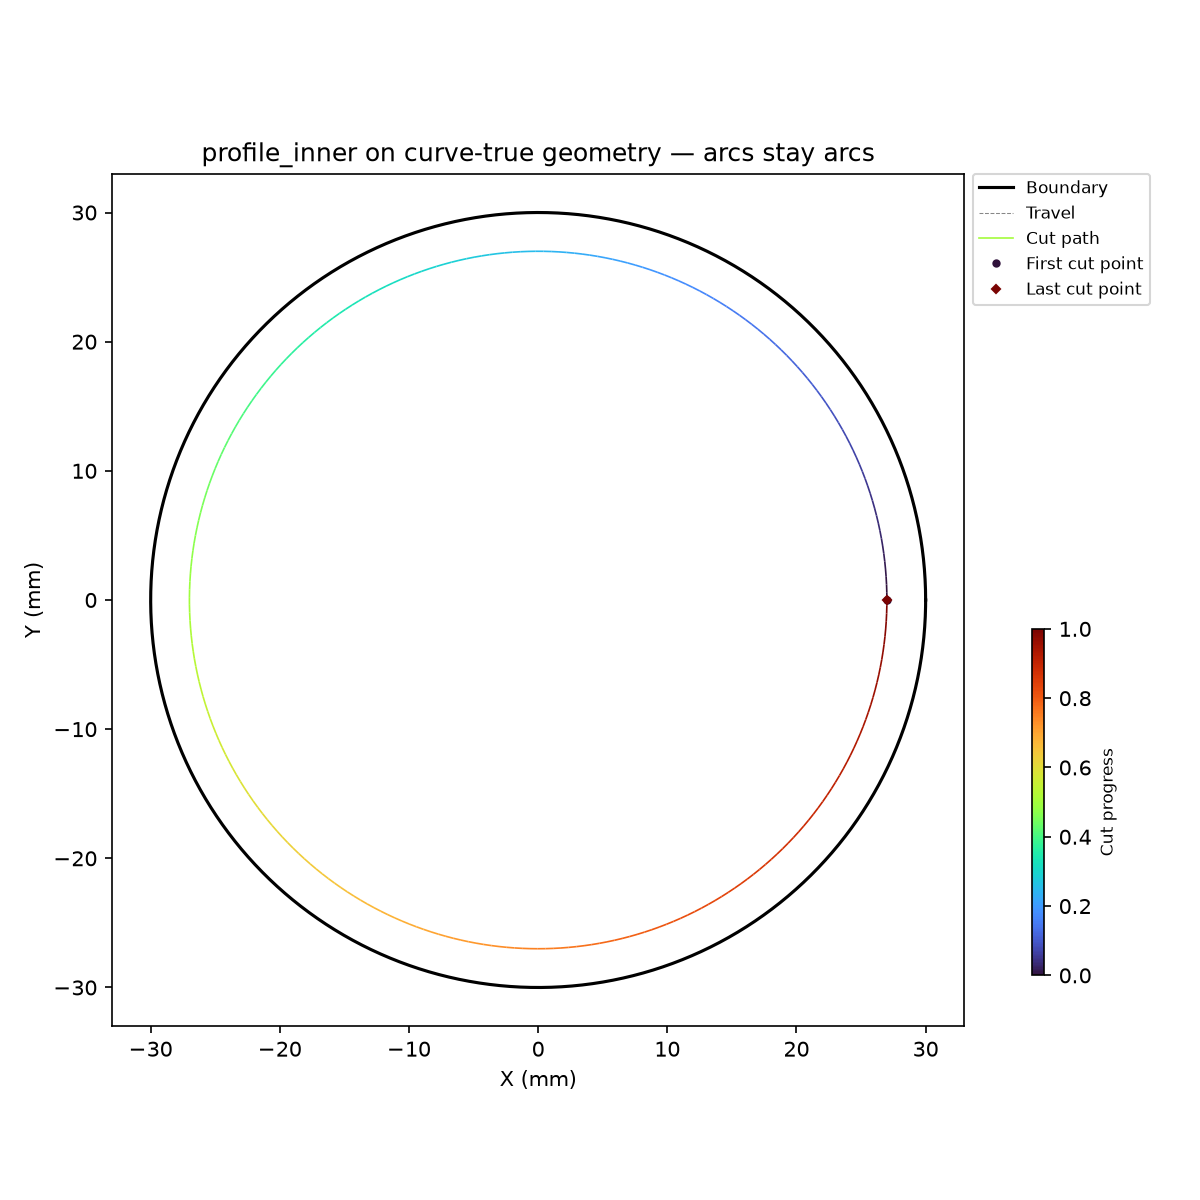
profile_inner on a curve-true circular boundary — the wall pass is emitted as true arcs.
profile_outer()
profile_outer(
    part: ops.part.Part,
    tool_radius: float,
    step_over: float,
    step_length: float,
    target_z: float,
    safe_z: float,
    wall_margin: float,
    cut_feed_rate: int,
    cut_power: float,
    start_pos: tuple[float, float] | None = None,
    cut_direction: str = 'ccw',
    stock_to_leave: float = 0,
    engagement_area_threshold: float = 0,
    engagement_angle_threshold: float = 3.141592653589793,
    trace_path: str | None = None,
    plunge_feed_rate: int | None = None,
) -> ops.assembly.AssemblyResult
Profile the outer boundary of a pocket.
Walks a tool around the grown boundary (offset outward by tool radius). The path stays approximately one tool radius outside the original boundary, removing any excess stock on the outer side. Returns an AssemblyResult with the profiling move sequence.
| Parameter | Type | Description |
|---|---|---|
part | ops.part.Part | The part whose cleared field tracks accumulated workpiece state and whose geometry defines the pocket boundary. |
tool_radius | float | Tool radius in mm. |
step_over | float | Radial step-over between passes (mm). |
step_length | float | Forward step length in mm. |
target_z | float | Cutting depth (Z). |
safe_z | float | Safe (rapid) Z height. |
wall_margin | float | Extra distance to keep from the wall (mm). |
cut_feed_rate | int | Feed rate in mm/min. |
cut_power | float | Spindle power (0.0–1.0). |
start_pos | tuple[float, float] | None = None | Optional override start (x, y) (default: first boundary vertex). |
cut_direction | str = 'ccw' | "cw" or "ccw" (default "ccw"). |
stock_to_leave | float = 0 | Stock left on wall for rough pass (mm, default 0.0). |
engagement_area_threshold | float = 0 | Overengagement area threshold (mm², 0 = auto). |
engagement_angle_threshold | float = 3.141592653589793 | Overengagement angle threshold (rad, default π). |
trace_path | str | None = None | Optional path to write a binary trace file (default None). |
plunge_feed_rate | int | None = None | Vertical plunge feed in mm/min for the descent into material (default None: cut feed). |
| Returns | ops.assembly.AssemblyResult | An AssemblyResult with the profiling path. |
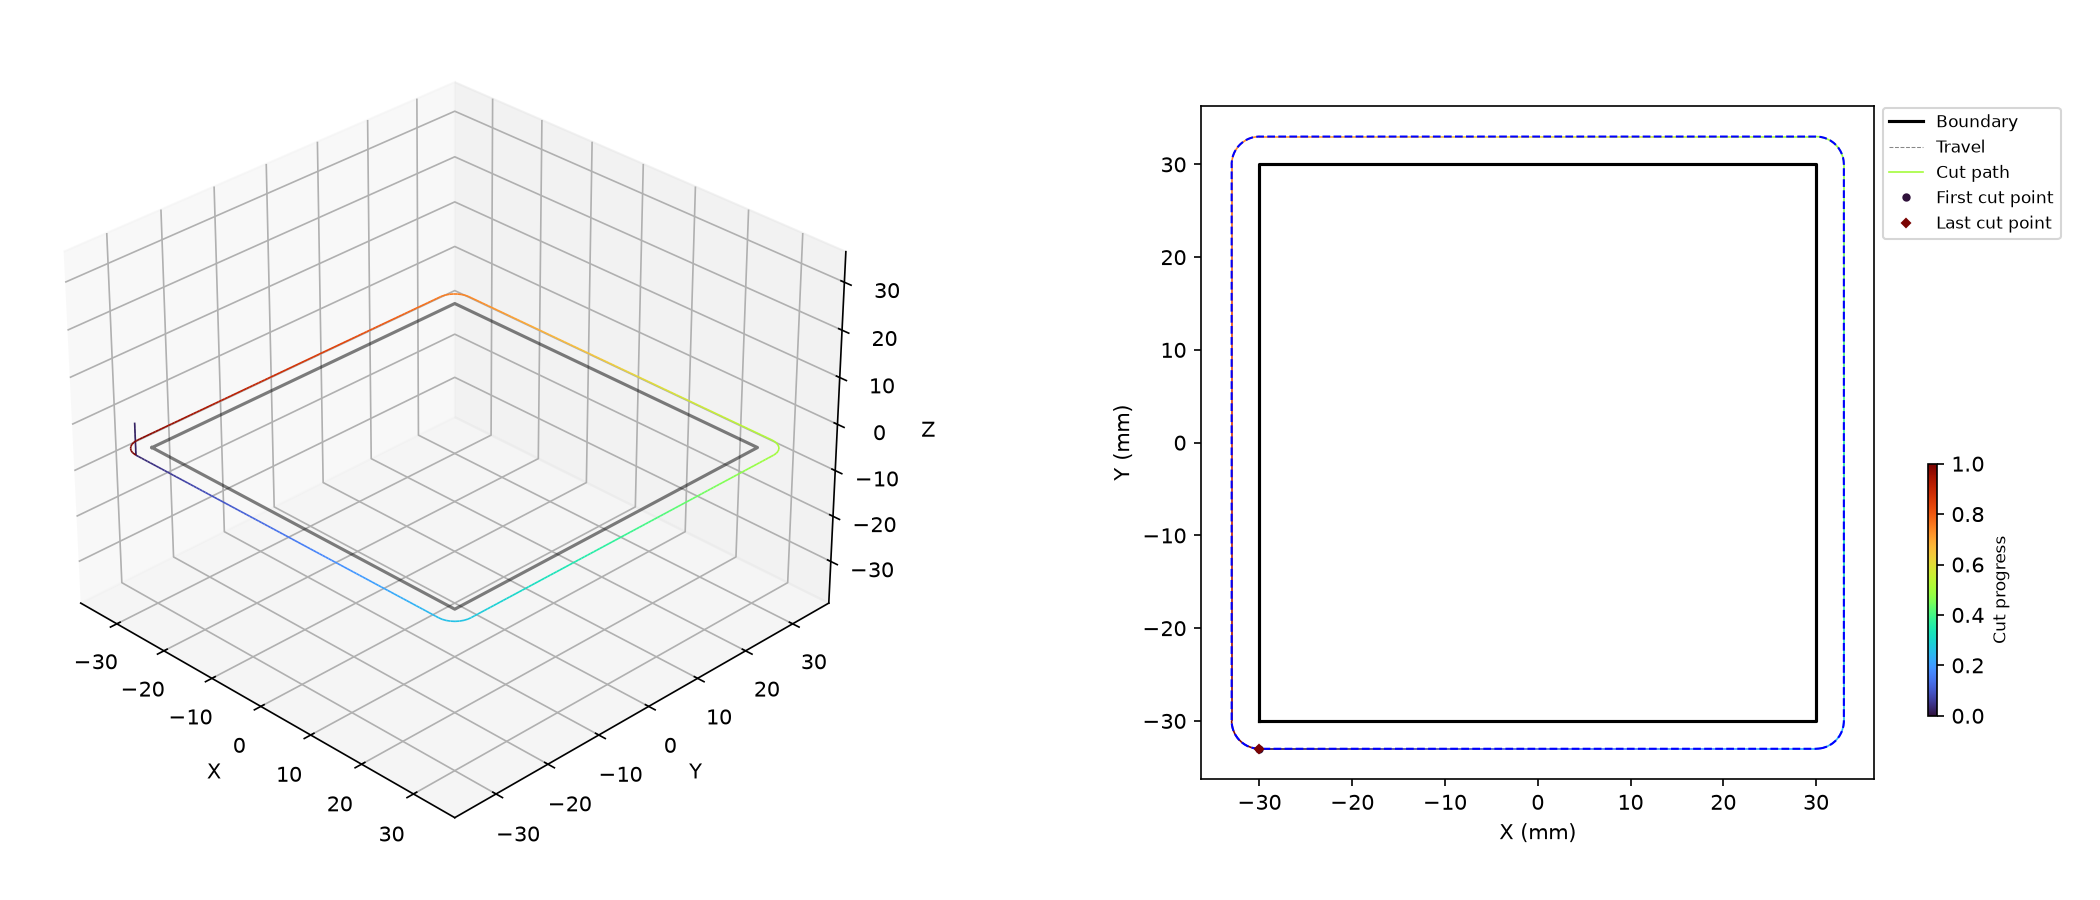
profile_outer on a rect pocket — 3D (left) and 2D top-down with offset tool-centre polygon (right).
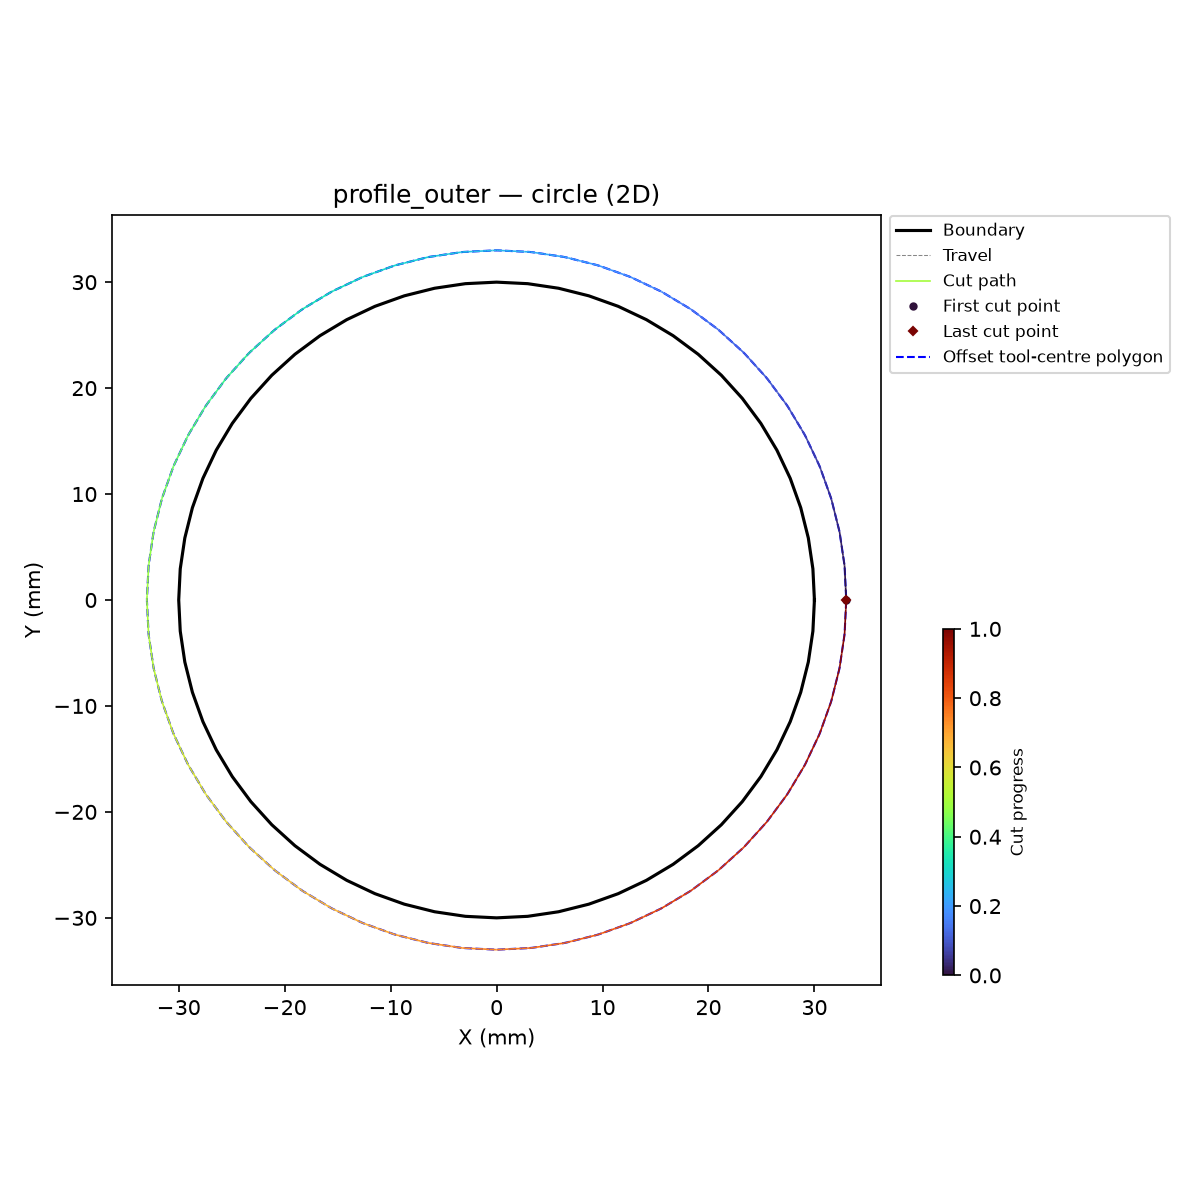
profile_outer on a circular boundary — smooth walk around the offset circle.
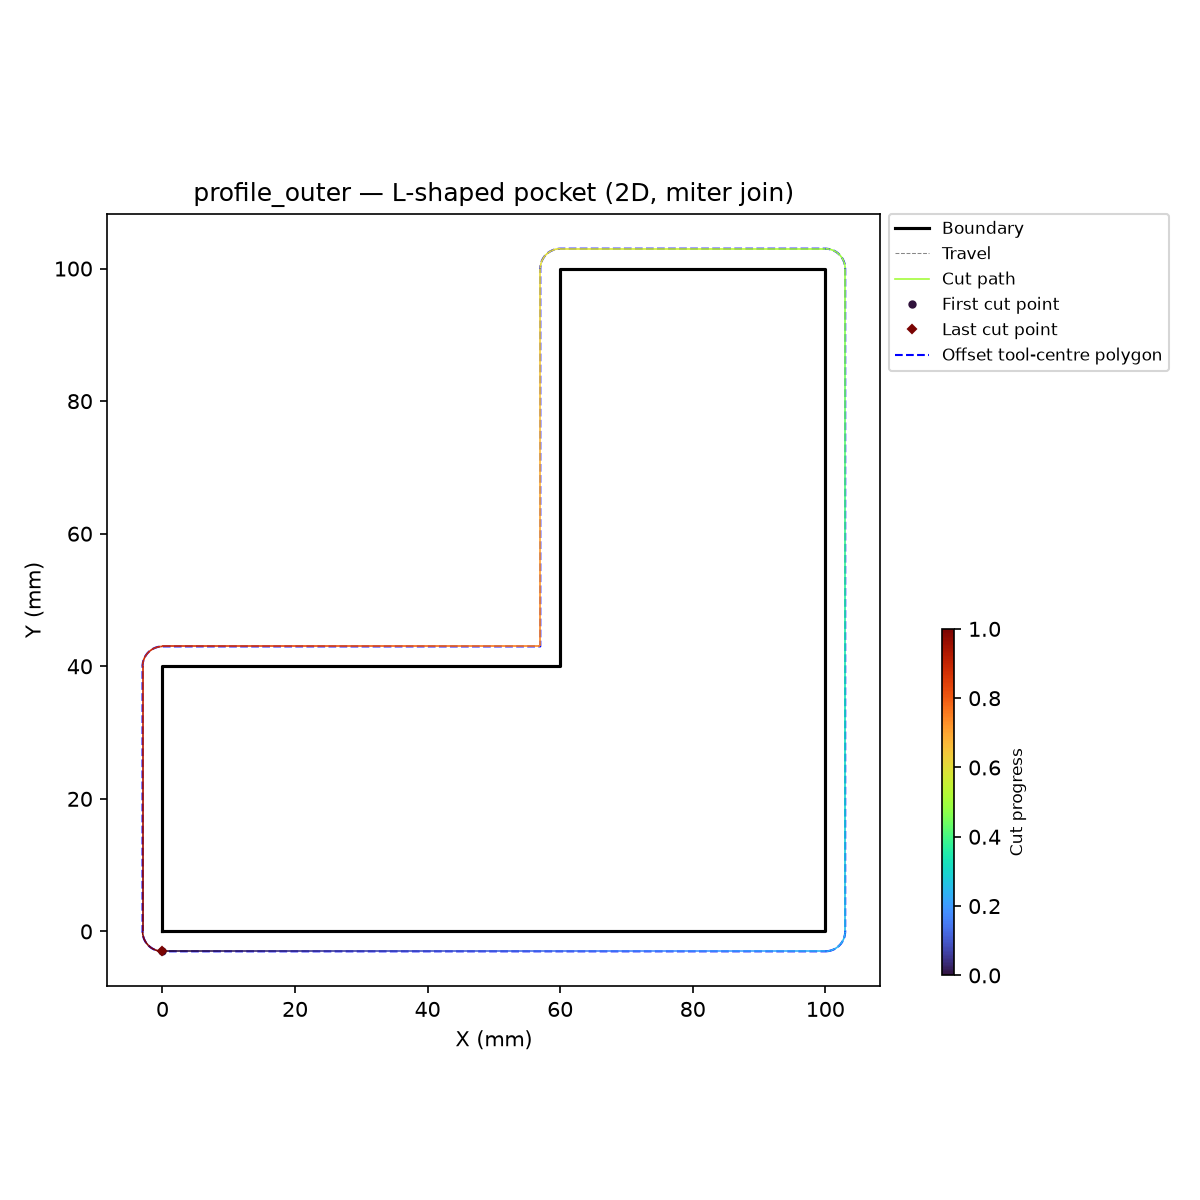
profile_outer on an L-shaped pocket with miter join at the concave corner.
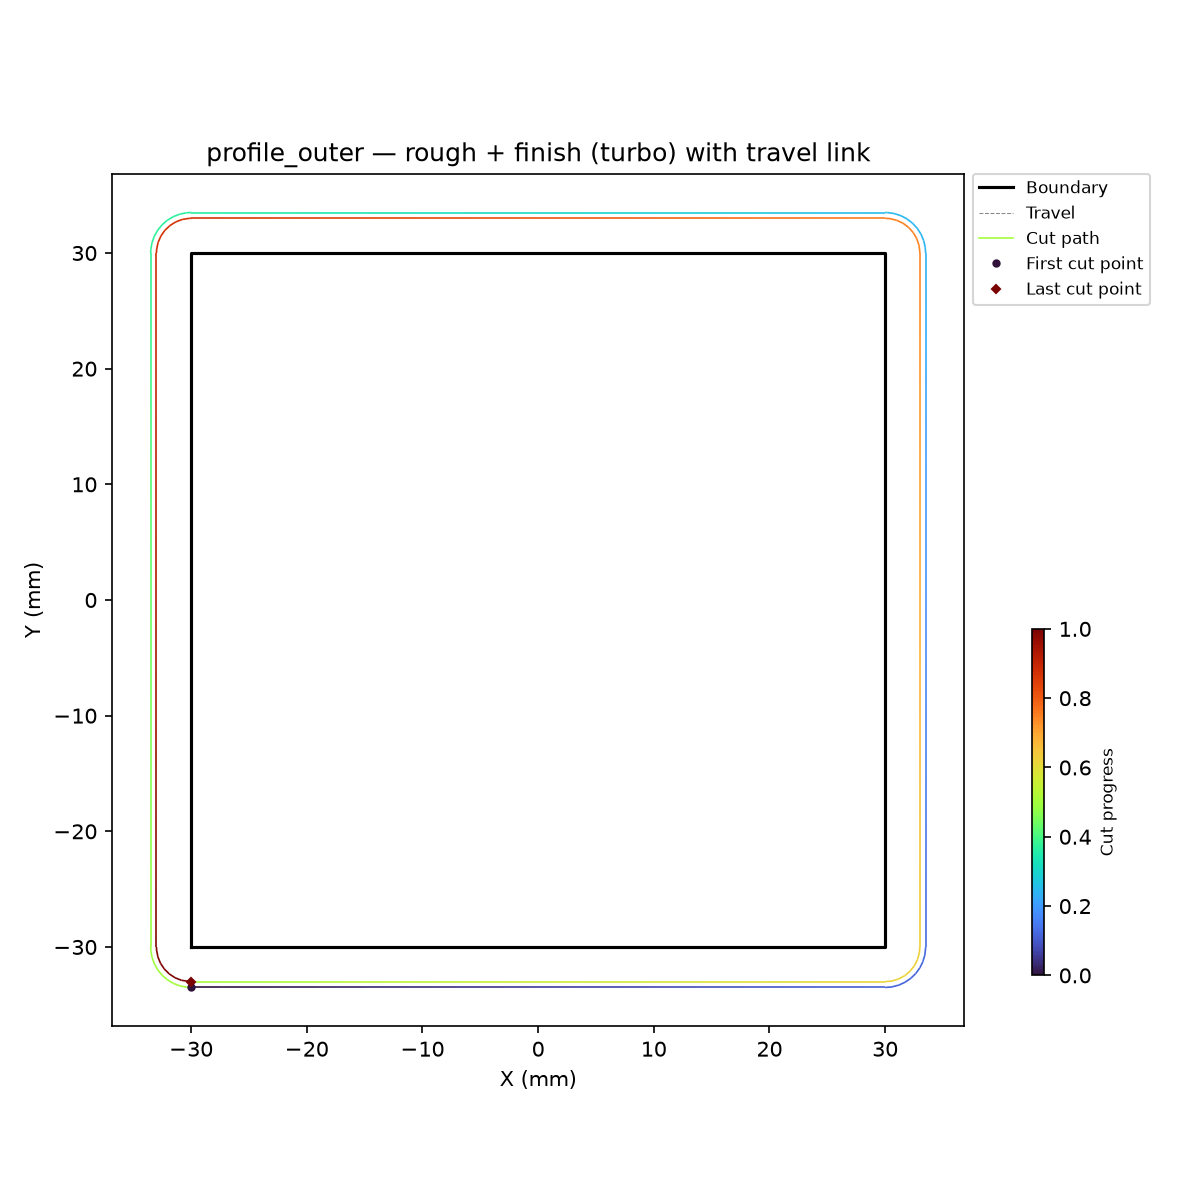
Two-pass profiling: rough (with stock, orange) + finish (red) on the same ClearedArea.