


raygeo.ops.assembly.drill
CountersinkSpec
Parameters for the countersink assembler: one conical plunge at one hole.
center
center: tuple[float, float]
dwell_ms
dwell_ms: float
rapid_z
rapid_z: float
safe_z
safe_z: float
target_diameter
target_diameter: float
Chamfer diameter produced at the surface (mm).
tip_angle
tip_angle: float
Included angle of the countersink cone in degrees.
z_surface
z_surface: float
DrillSpec
Parameters for the drill assembler: one cycle at one hole.
center
center: tuple[float, float]
diameter
diameter: float
Drill (and hole) diameter (mm).
dwell_ms
dwell_ms: float
Dwell at the bottom of every plunge (ms).
peck
peck: Optional[PeckParams]
rapid_z
rapid_z: float
Rapid plane just above the surface.
safe_z
safe_z: float
Safe rapid height.
spot
spot: bool
Marks the cycle as a spot drill.
target_z
target_z: float
Full-diameter depth of the hole (mm).
tip_angle
tip_angle: float
Drill point angle in degrees (tip compensation).
tip_compensate
tip_compensate: bool
When true (default), target_z is the full-diameter depth and the tip descends deeper by the tip
compensation. When false, target_z is the depth the tip reaches.
z_surface
z_surface: float
Surface Z the hole starts at.
PeckParams
Peck cycle parameters.
increment
increment: float
Axial depth per peck, measured from the surface (mm).
mode
mode: str
"FULL_RETRACT" (clear the flutes from the hole, G83) or "CHIP_BREAK" (small retract, G73).
retract_amount
retract_amount: float
Chip-break retract distance above the current depth (mm); only used with "CHIP_BREAK".
Functions
generate_countersink()
generate_countersink(
    part: ops.part.Part,
    center: tuple[float, float],
    tip_angle: float,
    target_diameter: float,
    z_surface: float = 0,
    rapid_z: float = 1,
    safe_z: float = 5,
    dwell_ms: float = 0,
    state: ops.state.State | None = None,
) -> ops.assembly.AssemblyResult
Generate one countersink cycle as explicit moves.
Plunges a conical countersink tool to the depth that produces target_diameter at the surface with
the given cone angle. The cycle is wrapped in a DRILL_CYCLE section.
| Parameter | Type | Description |
|---|---|---|
part | ops.part.Part | part owning the face the cycle is assembled on. |
center | tuple[float, float] | (x, y) of the hole. |
tip_angle | float | included angle of the countersink cone in degrees (e.g. 90). |
target_diameter | float | chamfer diameter at the surface (mm). |
z_surface | float = 0 | surface Z (default 0). |
rapid_z | float = 1 | rapid plane above the surface (default 1). |
safe_z | float = 5 | safe rapid height (default 5). |
dwell_ms | float = 0 | dwell at the bottom (ms). |
state | ops.state.State | None = None | optional machine state (feeds, spindle, coolant). |
| Returns | ops.assembly.AssemblyResult | An AssemblyResult with the cycle's moves. |
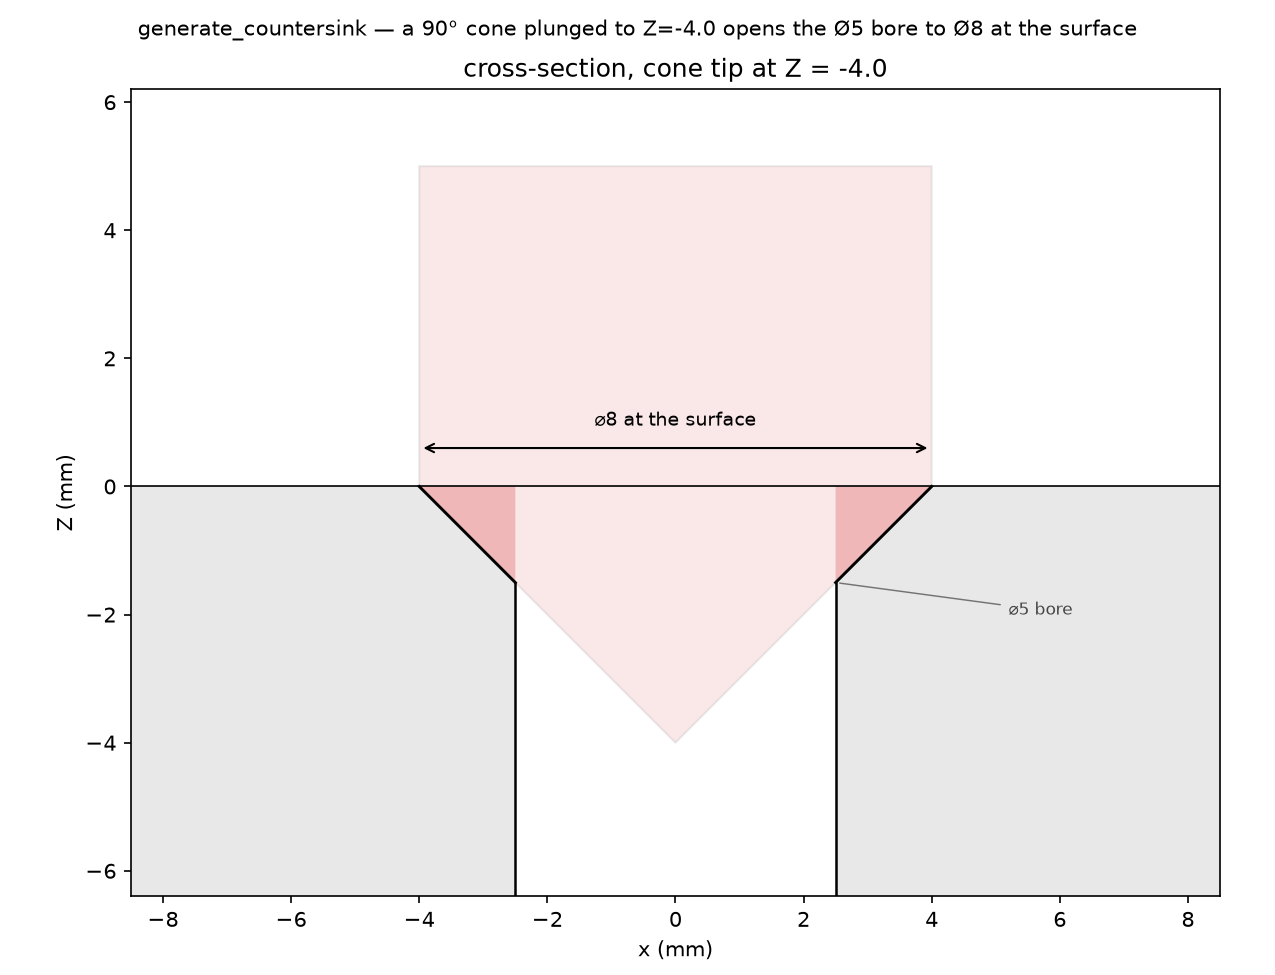
Countersink cross-section: the cone meets the surface exactly at the target diameter.
generate_drill()
generate_drill(
    part: ops.part.Part,
    center: tuple[float, float],
    diameter: float,
    target_z: float,
    tip_angle: float = 118,
    z_surface: float = 0,
    rapid_z: float = 1,
    safe_z: float = 5,
    peck: ops.assembly.drill.PeckParams | None = None,
    dwell_ms: float = 0,
    spot: bool = False,
    state: ops.state.State | None = None,
) -> ops.assembly.AssemblyResult
Generate one drilling cycle as explicit moves.
Rapids to the safe plane and the rapid plane, plunges at the plunge feed (with dwell), retracts per
the peck mode, and retracts to the safe plane. target_z is the full-diameter depth; the tip
descends deeper by the tip compensation (diameter / 2) / tan(tip_angle / 2). The whole cycle is
wrapped in a DRILL_CYCLE section so encoders can substitute a canned cycle.
| Parameter | Type | Description |
|---|---|---|
part | ops.part.Part | part owning the face the cycle is assembled on. |
center | tuple[float, float] | (x, y) of the hole. |
diameter | float | drill (and hole) diameter (mm). |
target_z | float | full-diameter depth (mm). |
tip_angle | float = 118 | drill point angle in degrees (default 118). |
z_surface | float = 0 | surface Z the hole starts at (default 0). |
rapid_z | float = 1 | rapid plane above the surface (default 1). |
safe_z | float = 5 | safe rapid height (default 5). |
peck | ops.assembly.drill.PeckParams | None = None | peck parameters; None drills in a single plunge. |
dwell_ms | float = 0 | dwell at the bottom of every plunge (ms). |
spot | bool = False | marks the cycle as a spot drill. |
state | ops.state.State | None = None | optional machine state (feeds, spindle, coolant). |
| Returns | ops.assembly.AssemblyResult | An AssemblyResult with the cycle's moves. |
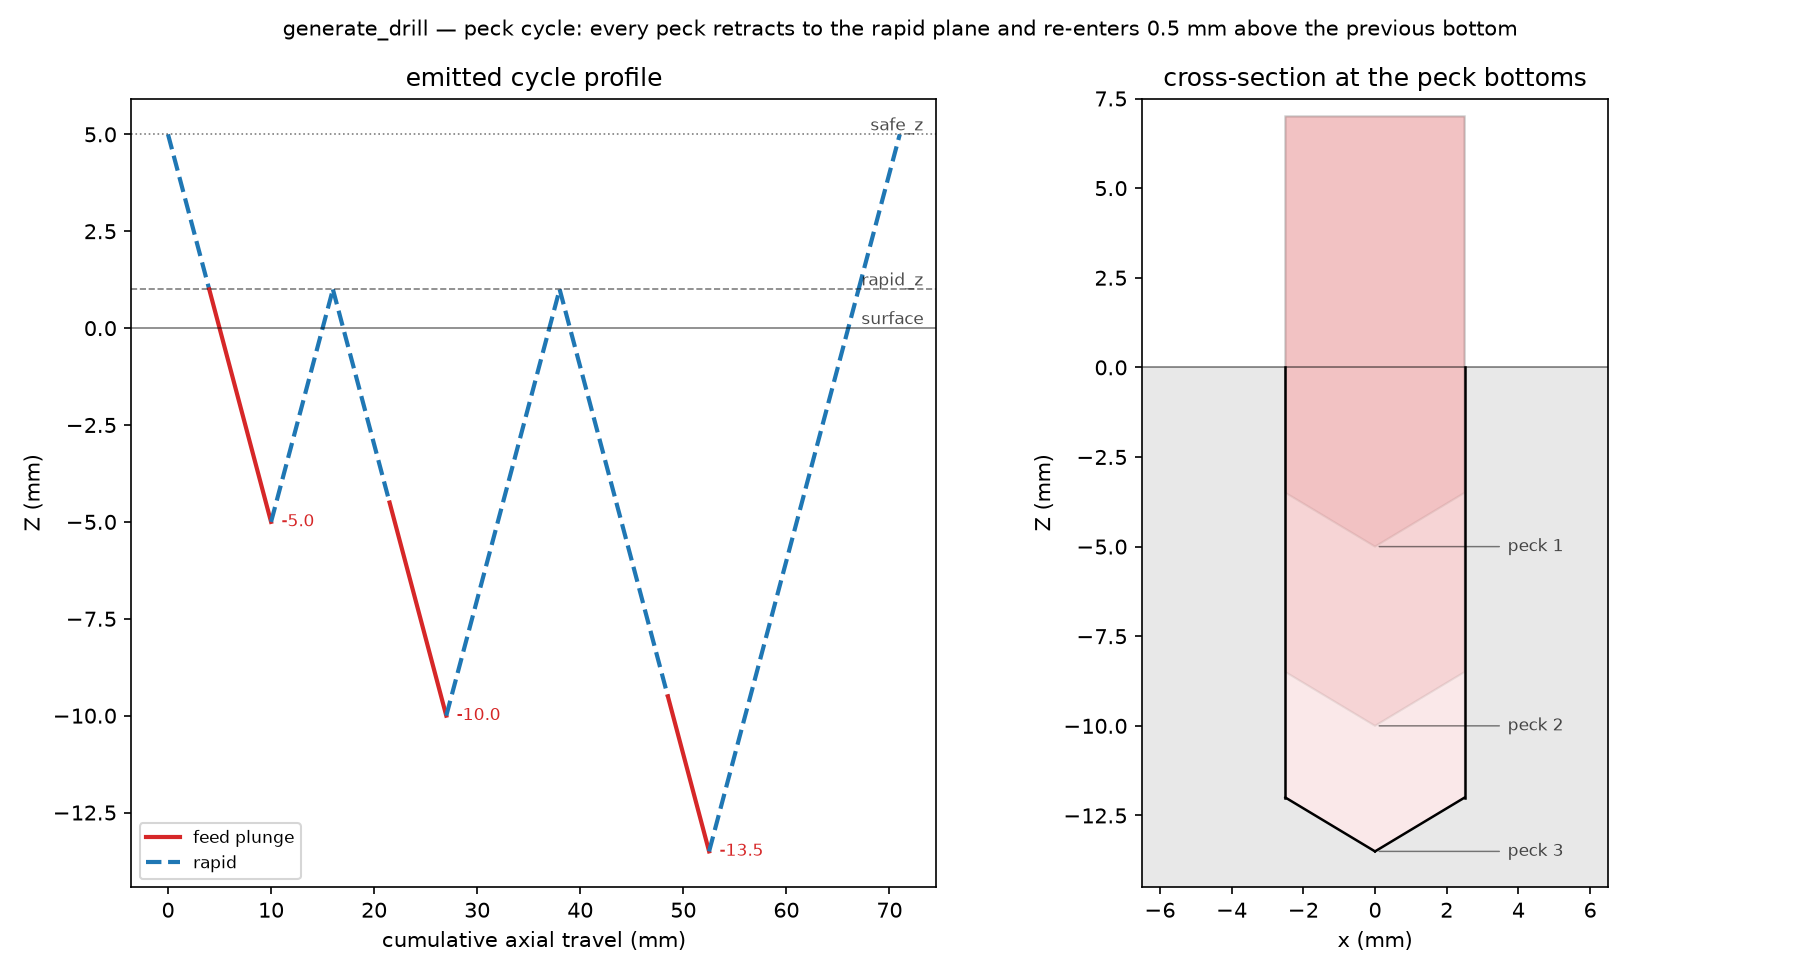
Peck cycle: emitted plunge/retract profile (left) and cross-section with tool ghosts (right).
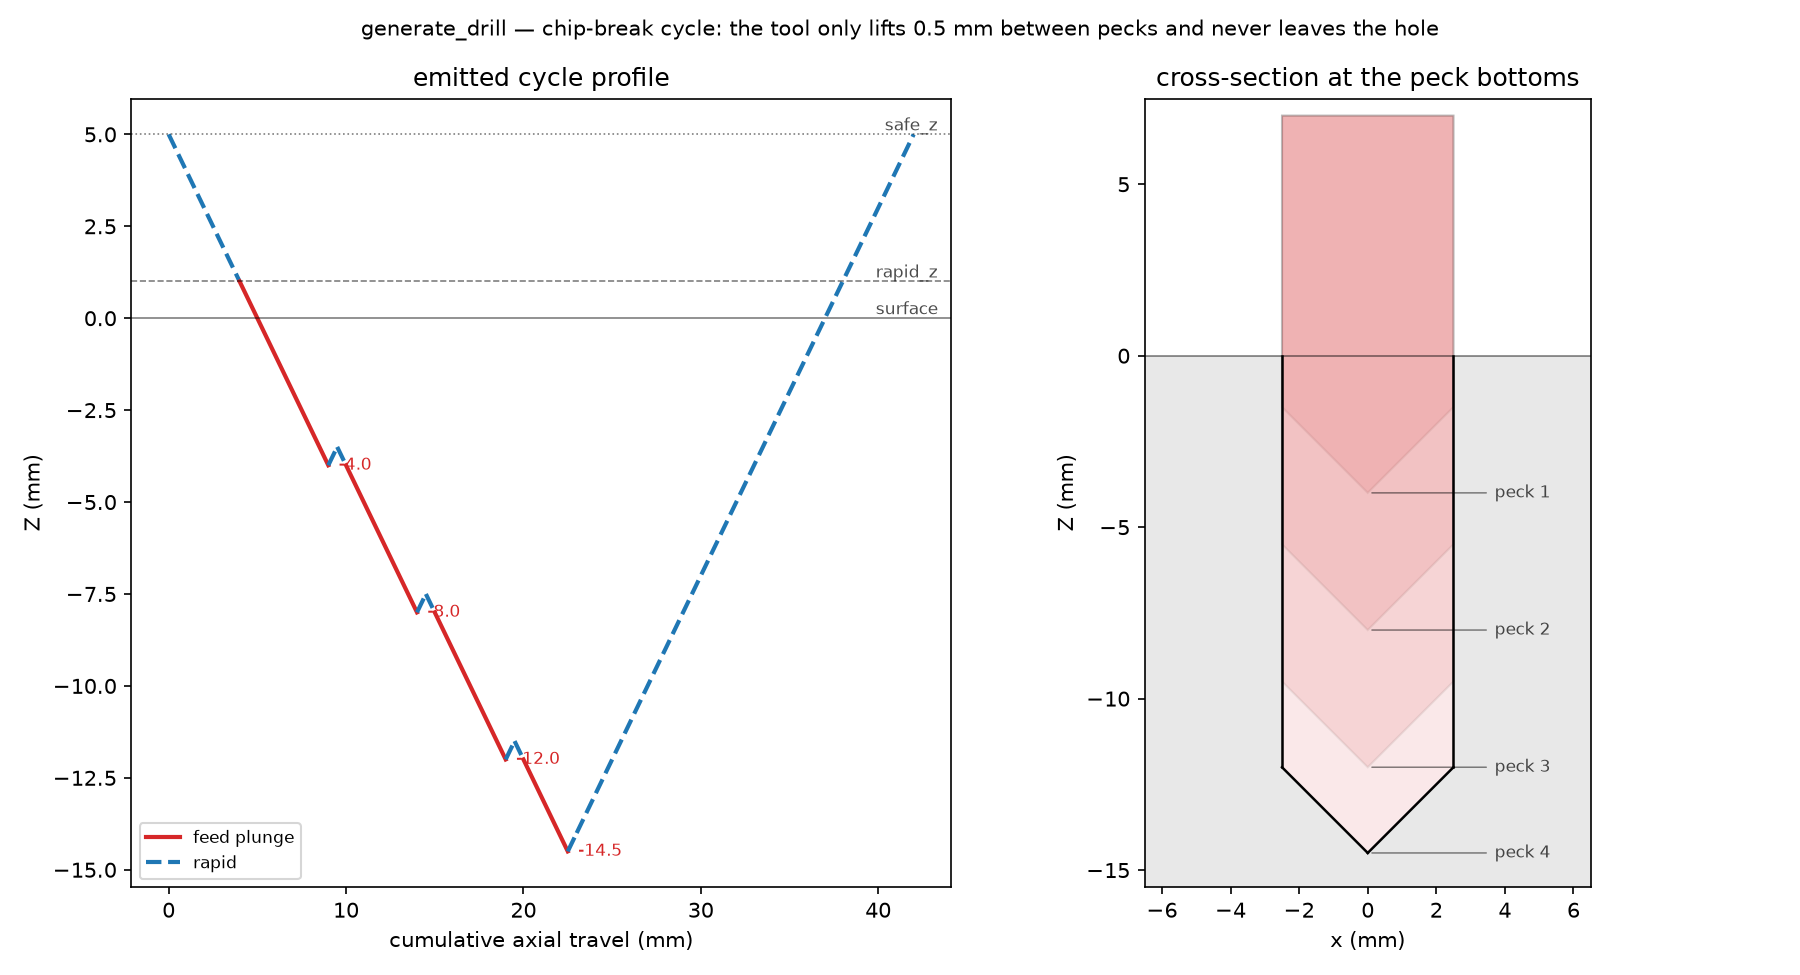
Chip-break cycle: profile and cross-section; the tool never leaves the hole between pecks.