


raygeo.cnc.plan.clearing
CNC clearing plan builder.
Produces a ~raygeo.cnc.plan.Plan organised as a BFS traversal of the pocket's region/passage graph.
ClearingWorkplanOptions
The tool and machining parameters plan_clearing plans from.
The pocket boundary and islands are read from the Part — this class carries only the tool and
machining parameters.
angular_step
angular_step: float
area_tolerance
area_tolerance: float
cut_direction
cut_direction: str
"cw" or "ccw": how passes walk their loops.
feed_rate
feed_rate: Optional[float]
Cut feed rate (mm/min) the plan's moves carry; None leaves the cut state unset, for embedders that
map feeds themselves.
finishing
finishing: bool
max_deflection_deg
max_deflection_deg: float
max_entry_angle_deg
max_entry_angle_deg: float
Steepest entry descent in degrees; <= 0 keeps the planner's historical entry behaviour.
plunge_feed
plunge_feed: Optional[float]
Vertical plunge feed (mm/min) for descents into material; None falls back to the cut feed.
plunge_pitch
plunge_pitch: float
safe_margin
safe_margin: float
safe_z
safe_z: float
step_length
step_length: float
step_over
step_over: float
stock_to_leave
stock_to_leave: float
target_z
target_z: float
tool_radius
tool_radius: float
travel_mode
travel_mode: str
"cleared_area" or "safe_z": how travels are routed.
wall_margin
wall_margin: float
for_tool()
for_tool(
    tool_radius: float,
    step_over: float,
    target_z: float,
    safe_z: float,
) -> ClearingWorkplanOptions
Options carrying the planner's canonical scales for tool_radius: a fifth-of-a-radius step length,
a fifth-of-a-radius safe margin, a plunge pitch of a third of the radius, and the planner's angular
and area tuning (0.1 rad angular steps, a 1.0 mm² area tolerance, 30° max deflection). The
per-operation fields keep their neutral defaults; set step_over, wall_margin, stock_to_leave,
finishing, max_entry_angle_deg and the feeds on the result.
| Parameter | Type | Description |
|---|---|---|
tool_radius | float | Tool radius in mm. |
step_over | float | Radial step-over between passes (mm). |
target_z | float | Cutting depth (Z). |
safe_z | float | Safe (rapid) Z height. |
| Returns | ClearingWorkplanOptions |
Functions
plan_clearing()
plan_clearing(
    part: part.Part,
    face_id: str = '',
    tool_radius: float = 3.0,
    step_over: float = 2.0,
    step_length: float = 0.6,
    target_z: float = -5.0,
    safe_z: float = 2.0,
    wall_margin: float = 0.0,
    safe_margin: float = 1.0,
    stock_to_leave: float = 0.0,
    plunge_pitch: float = 1.0,
    angular_step: float = 0.1,
    area_tolerance: float = 1.0,
    max_deflection_deg: float = 30.0,
    finishing: bool = False,
    feed_rate: Optional[float] = None,
    plunge_feed: Optional[float] = None,
    max_entry_angle_deg: float = 0.0,
    cut_direction: str = 'ccw',
    travel_mode: str = 'cleared_area',
) -> plan.Plan
| Parameter | Type | Description |
|---|---|---|
part | part.Part | |
face_id | str = '' | |
tool_radius | float = 3.0 | |
step_over | float = 2.0 | |
step_length | float = 0.6 | |
target_z | float = -5.0 | |
safe_z | float = 2.0 | |
wall_margin | float = 0.0 | |
safe_margin | float = 1.0 | |
stock_to_leave | float = 0.0 | |
plunge_pitch | float = 1.0 | |
angular_step | float = 0.1 | |
area_tolerance | float = 1.0 | |
max_deflection_deg | float = 30.0 | |
finishing | bool = False | |
feed_rate | Optional[float] = None | |
plunge_feed | Optional[float] = None | |
max_entry_angle_deg | float = 0.0 | |
cut_direction | str = 'ccw' | |
travel_mode | str = 'cleared_area' | |
| Returns | plan.Plan |
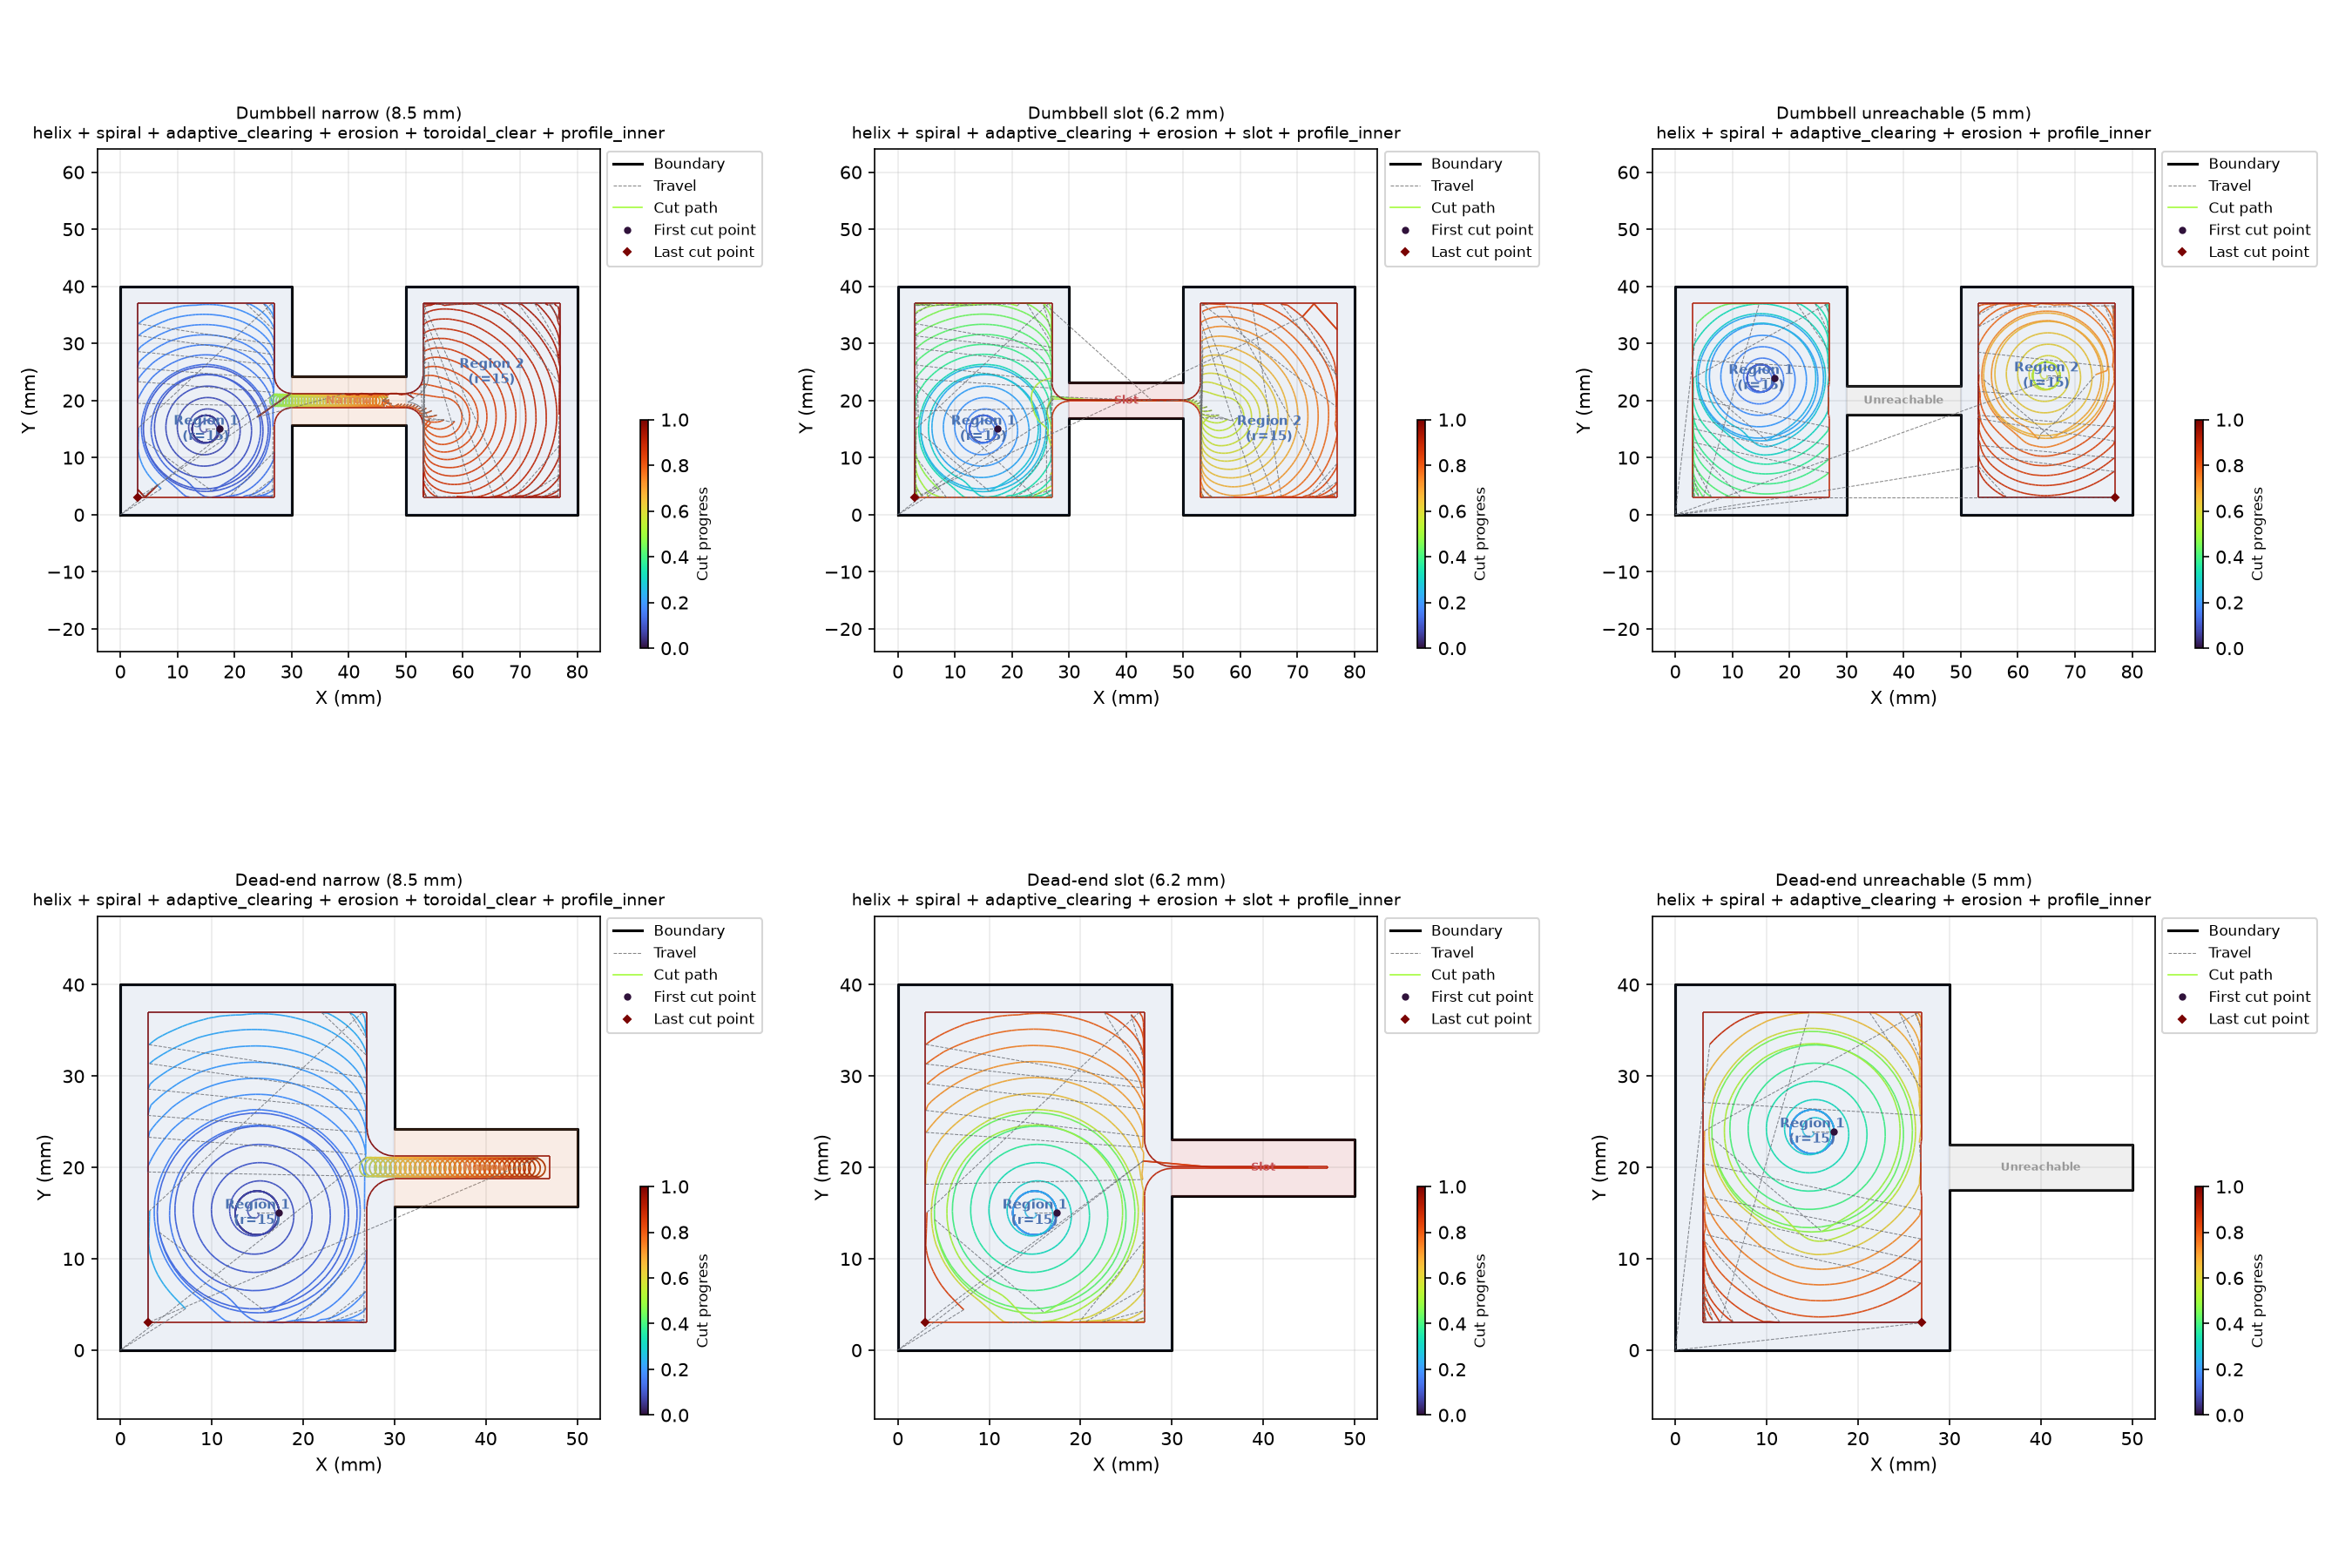
Clearing workplan: narrow passage (ToroidalClear), slot (Slot), dual-entry dumbbell (Unreachable).
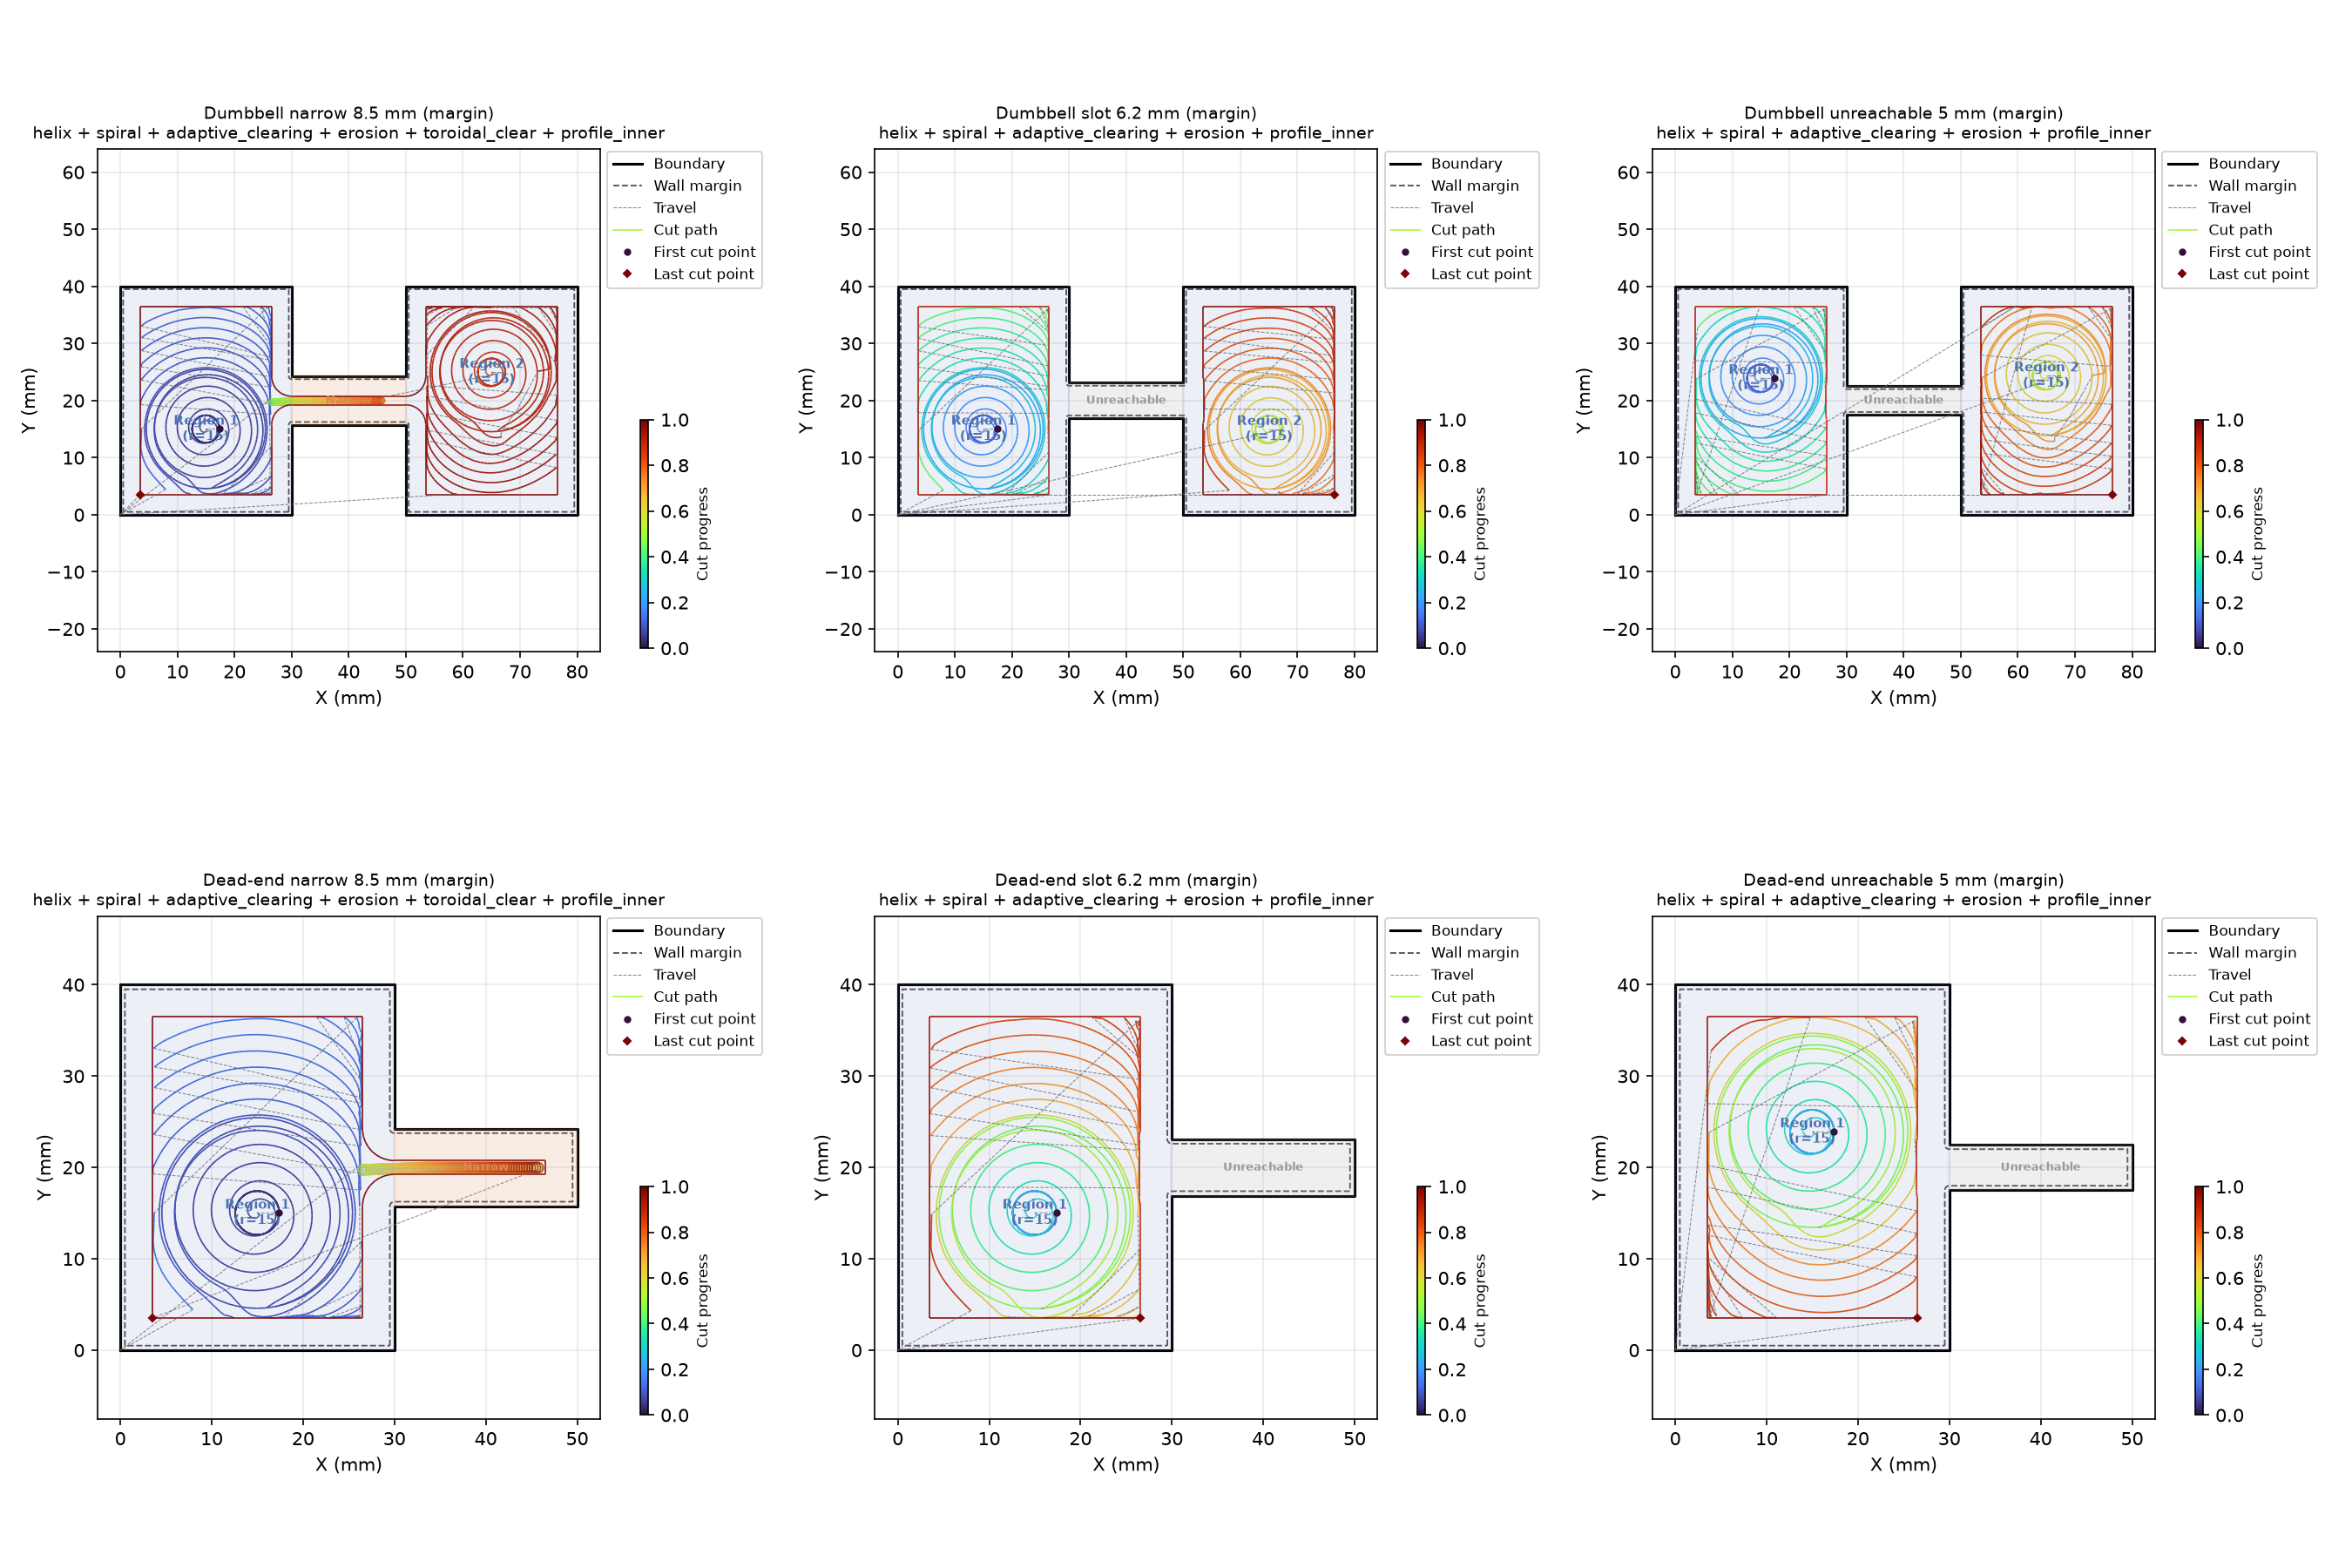
The same pockets with a 0.5 mm wall margin: too-narrow passages stay uncut.
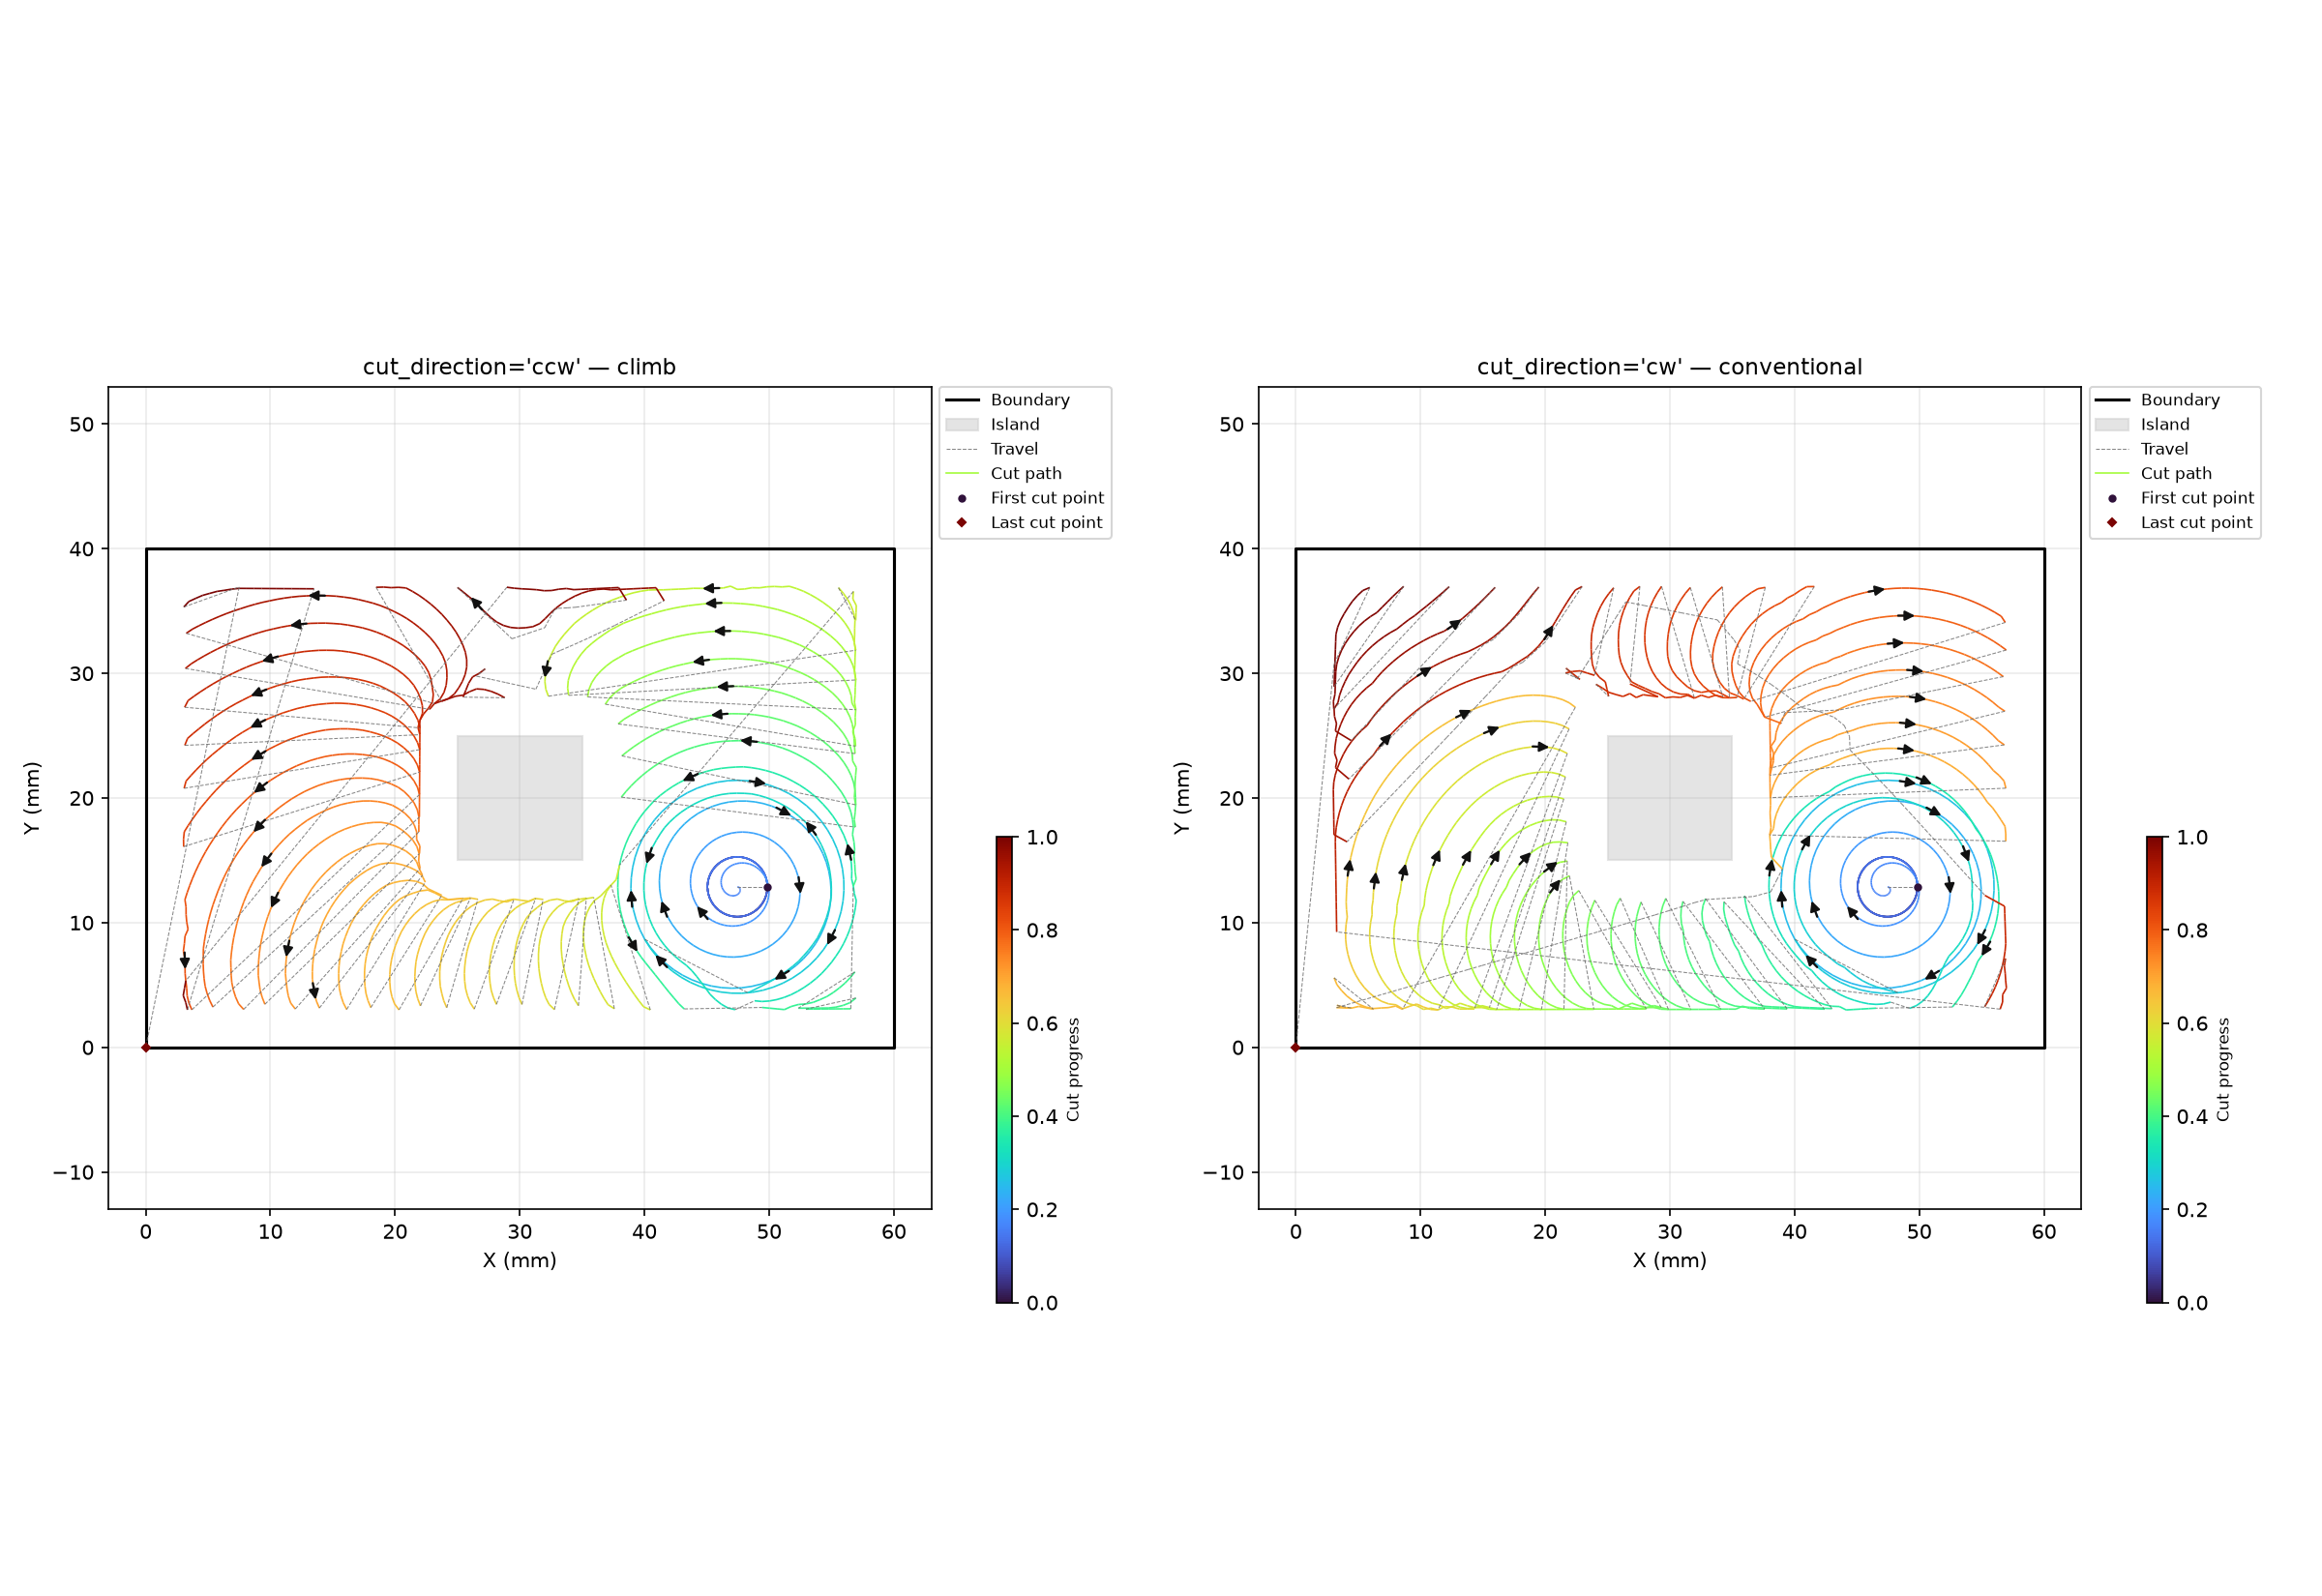
Cut direction: climb ('ccw', left) vs conventional ('cw', right) — arrows mark the walk.