


raygeo.geo.shape.arc
Arc geometry queries and conversions.
Provides bounding rectangle computation, intersection tests (arc-rect, arc-circle, arc-polygons), arc linearization into line segments for rendering or further processing, angle utilities (normalize, direction, containment), and arc midpoint / closest-point lookups.
Functions
does_arc_intersect_circle()
does_arc_intersect_circle(
    arc_start: types.Point,
    arc_end: types.Point,
    arc_center: types.Point,
    clockwise: bool,
    circle_center: types.Point,
    circle_radius: float,
) -> bool
Check if an arc intersects a circle.
| Parameter | Type | Description |
|---|---|---|
arc_start | types.Point | Arc start point (x, y). |
arc_end | types.Point | Arc end point (x, y). |
arc_center | types.Point | Arc center point (x, y). |
clockwise | bool | Whether the arc is clockwise. |
circle_center | types.Point | Circle center (x, y). |
circle_radius | float | Circle radius. |
| Returns | bool | True if the arc intersects the circle. |
| Complexity | O(n) time, O(1) space |
does_arc_intersect_rect()
does_arc_intersect_rect(
    arc_start: types.Point,
    arc_end: types.Point,
    arc_center: types.Point,
    clockwise: bool,
    rect: types.Rect,
) -> bool
Check if an arc intersects a rectangle.
| Parameter | Type | Description |
|---|---|---|
arc_start | types.Point | Arc start point (x, y). |
arc_end | types.Point | Arc end point (x, y). |
arc_center | types.Point | Arc center point (x, y). |
clockwise | bool | Whether the arc is clockwise. |
rect | types.Rect | Rectangle (x_min, y_min, x_max, y_max). |
| Returns | bool | True if the arc intersects the rectangle. |
| Complexity | O(n) time, O(1) space |
get_arc_angles()
get_arc_angles(
    start: types.Point,
    end: types.Point,
    center: types.Point,
    clockwise: bool,
) -> types.Point3D
Get the start, end, and sweep angles of an arc.
| Parameter | Type | Description |
|---|---|---|
start | types.Point | Arc start point (x, y). |
end | types.Point | Arc end point (x, y). |
center | types.Point | Arc center point (x, y). |
clockwise | bool | Whether the arc is clockwise. |
| Returns | types.Point3D | Tuple of (start_angle, end_angle, sweep_angle) in radians. |
| Complexity | O(1) time, O(1) space |
get_arc_bounds()
get_arc_bounds(
    start: types.Point,
    end: types.Point,
    center: types.Point,
    clockwise: bool,
) -> types.Rect
Get the bounding rectangle of an arc.
| Parameter | Type | Description |
|---|---|---|
start | types.Point | Arc start point (x, y). |
end | types.Point | Arc end point (x, y). |
center | types.Point | Arc center point (x, y). |
clockwise | bool | Whether the arc is clockwise. |
| Returns | types.Rect | Bounding rectangle as (x_min, y_min, x_max, y_max). |
| Complexity | O(1) time, O(1) space |
get_arc_closest_point()
get_arc_closest_point(
    arc_cmd: Any,
    start_pos: types.Point3D,
    x: float,
    y: float,
) -> Optional[tuple[float, types.Point, float]]
Get the closest point on an arc to a given point.
| Parameter | Type | Description |
|---|---|---|
arc_cmd | Any | Arc command row or MockArc-like object. |
start_pos | types.Point3D | Start position (x, y, z). |
x | float | X coordinate of target point. |
y | float | Y coordinate of target point. |
| Returns | Optional[tuple[float, types.Point, float]] | Tuple of (parameter, closest_point, distance) or None. |
| Complexity | O(n) time, O(1) space |
get_arc_direction()
get_arc_direction(
    center: types.Point,
    start: types.Point,
    mouse: types.Point,
) -> bool
Get the direction (CW/CCW) of an arc at a mouse point.
| Parameter | Type | Description |
|---|---|---|
center | types.Point | Arc center (x, y). |
start | types.Point | Arc start point (x, y). |
mouse | types.Point | Mouse point (x, y). |
| Returns | bool | True if clockwise, False if counter-clockwise. |
| Complexity | O(1) time, O(1) space |
get_arc_length()
get_arc_length(
    start_pos: types.Point,
    end_pos: types.Point,
    center_offset: types.Point,
    clockwise: bool,
) -> float
Compute the arc length of a circular arc.
| Parameter | Type | Description |
|---|---|---|
start_pos | types.Point | Start point (x, y). |
end_pos | types.Point | End point (x, y). |
center_offset | types.Point | Center offset (i, j) from start. |
clockwise | bool | True for clockwise, False for counter-clockwise. |
| Returns | float | Arc length. |
| Complexity | O(1) time, O(1) space |
get_arc_midpoint()
get_arc_midpoint(
    start: types.Point,
    end: types.Point,
    center: types.Point,
    clockwise: bool,
) -> types.Point
Get the midpoint of an arc.
| Parameter | Type | Description |
|---|---|---|
start | types.Point | Arc start point (x, y). |
end | types.Point | Arc end point (x, y). |
center | types.Point | Arc center point (x, y). |
clockwise | bool | Whether the arc is clockwise. |
| Returns | types.Point | Midpoint (x, y). |
| Complexity | O(1) time, O(1) space |
get_arc_sweep()
get_arc_sweep(start_angle: float, end_angle: float, clockwise: bool) -> float
Compute the signed sweep angle for an arc.
Handles direction (CW/CCW) and full-circle detection.
| Parameter | Type | Description |
|---|---|---|
start_angle | float | Start angle in radians. |
end_angle | float | End angle in radians. |
clockwise | bool | Whether the arc is clockwise. |
| Returns | float | Signed sweep angle in radians. |
| Complexity | O(1) time, O(1) space |
get_arc_through_point()
get_arc_through_point(
    t_start: types.Point,
    t_end: types.Point,
    t_mid: types.Point,
    center: types.Point,
    radius: float,
) -> types.Polygon
Build a circular arc through three points around a centre.
Returns a polyline approximation of the arc from t_start to t_end that passes through t_mid, with the given centre and radius.
| Parameter | Type | Description |
|---|---|---|
t_start | types.Point | Arc start point (x, y). |
t_end | types.Point | Arc end point (x, y). |
t_mid | types.Point | Point the arc must pass through (x, y). |
center | types.Point | Arc centre (x, y). |
radius | float | Arc radius. |
| Returns | types.Polygon | Polyline approximation as list of (x, y) points. |
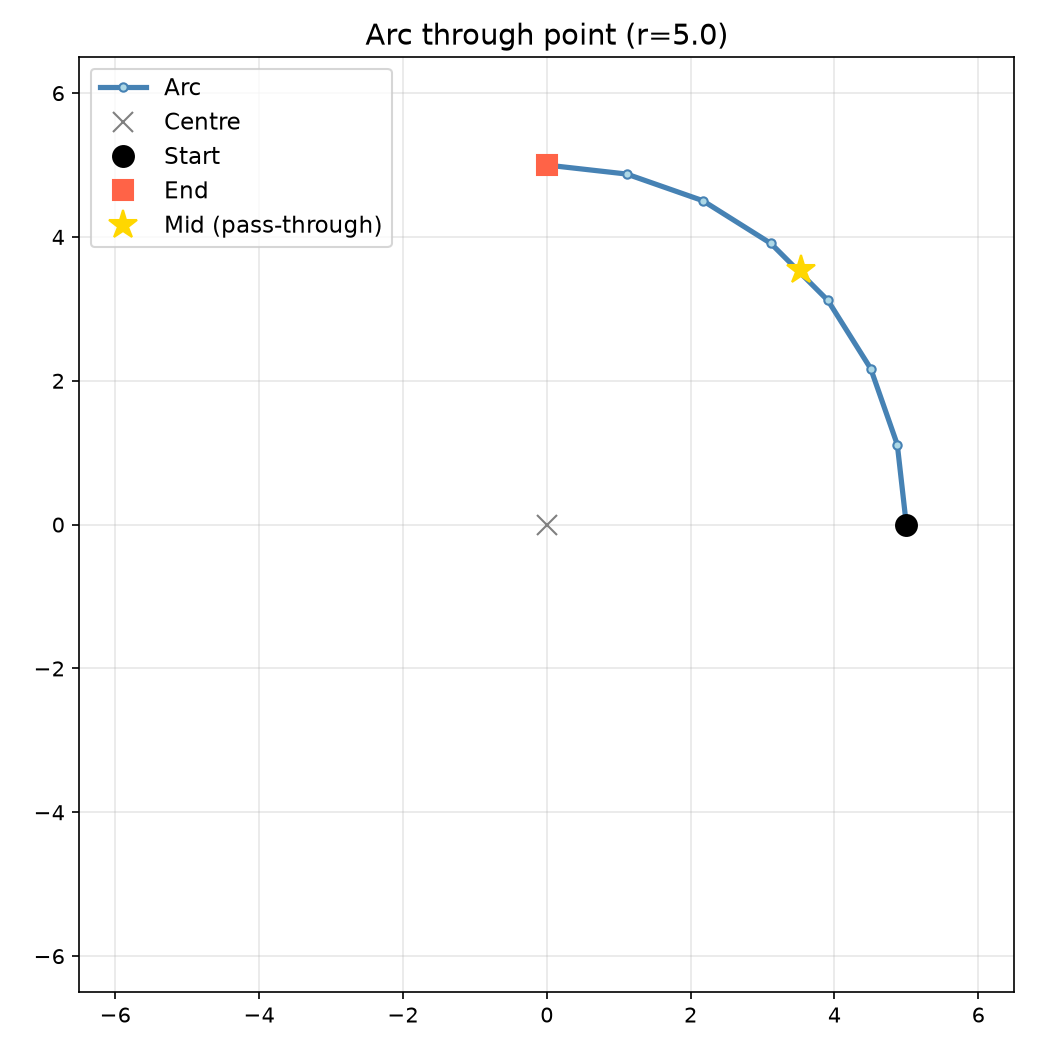
Construct a circular arc through a given point
get_polyline_turn_sign()
get_polyline_turn_sign(polyline: Sequence[types.Point]) -> float
Determine the turn direction of a polyline at its midpoint.
Computes the cross product of the edge vectors just before and just after the midpoint vertex.
Returns +1.0 for a counter-clockwise (left) turn and -1.0 for a clockwise (right) turn.
| Parameter | Type | Description |
|---|---|---|
polyline | Sequence[types.Point] | Open polyline as (x, y) points. |
| Returns | float | +1.0 (CCW) or -1.0 (CW). |
| Complexity | O(1) time, O(1) space |
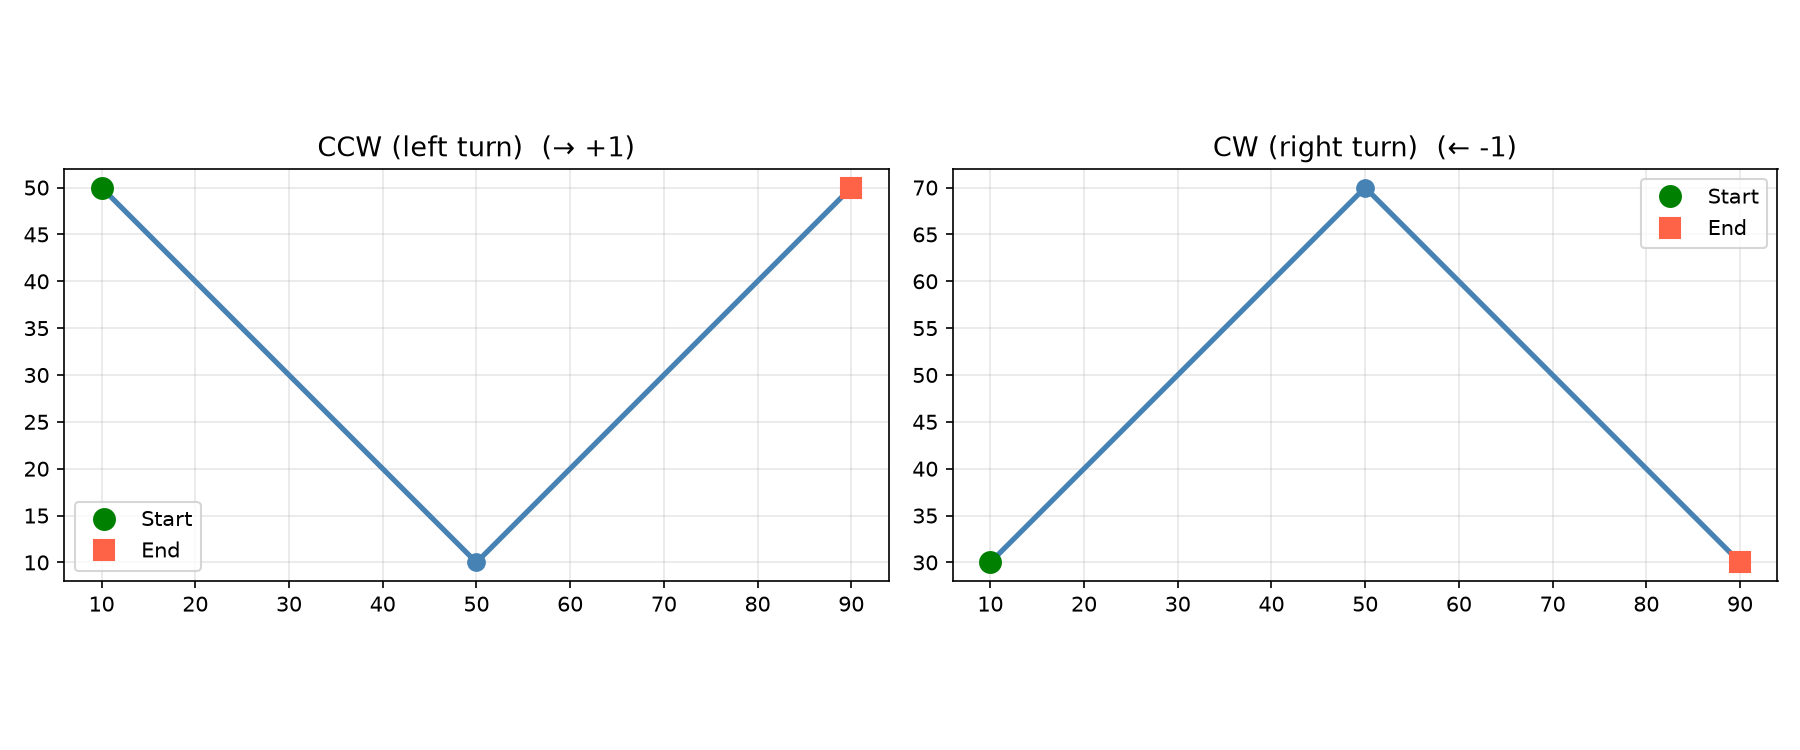
Determine turn direction of a polyline at its midpoint vertex
is_angle_between()
is_angle_between(
    angle: float,
    start: float,
    end: float,
    clockwise: bool,
) -> bool
Check if an angle is between two other angles.
| Parameter | Type | Description |
|---|---|---|
angle | float | Angle to test. |
start | float | Start angle. |
end | float | End angle. |
clockwise | bool | Whether the arc is clockwise. |
| Returns | bool | True if angle is between start and end. |
| Complexity | O(1) time, O(1) space |
is_arc_clockwise()
is_arc_clockwise(
    points: Sequence[types.Point2DOr3D],
    center: types.Point2DOr3D,
) -> bool
Check if an arc is clockwise.
| Parameter | Type | Description |
|---|---|---|
points | Sequence[types.Point2DOr3D] | Sequence of (x, y) points on the arc. |
center | types.Point2DOr3D | Arc center (x, y). |
| Returns | bool | True if the arc is clockwise. |
| Complexity | O(n) time, O(1) space |
is_arc_inside_polygons()
is_arc_inside_polygons(
    arc_start: types.Point,
    arc_end: types.Point,
    arc_center: types.Point,
    clockwise: bool,
    polygons: Any,
) -> bool
Check if an arc is inside a set of polygons.
| Parameter | Type | Description |
|---|---|---|
arc_start | types.Point | Arc start point (x, y). |
arc_end | types.Point | Arc end point (x, y). |
arc_center | types.Point | Arc center point (x, y). |
clockwise | bool | Whether the arc is clockwise. |
polygons | Any | List of polygons to check against. |
| Returns | bool | True if the arc is inside all polygons. |
| Complexity | O(n * m) time, O(1) space |
linearize_arc()
linearize_arc(
    arc_cmd: Any,
    start_point: types.Point3D,
    resolution: float = 0.1,
) -> list[tuple[types.Point3D, types.Point3D]]
Linearize an arc into line segments.
| Parameter | Type | Description |
|---|---|---|
arc_cmd | Any | Arc command row or MockArc-like object. |
start_point | types.Point3D | Start point (x, y, z). |
resolution | float = 0.1 | Maximum segment length. |
| Returns | list[tuple[types.Point3D, types.Point3D]] | List of (p1, p2) segment pairs. |
| Complexity | O(n) time, O(n) space |
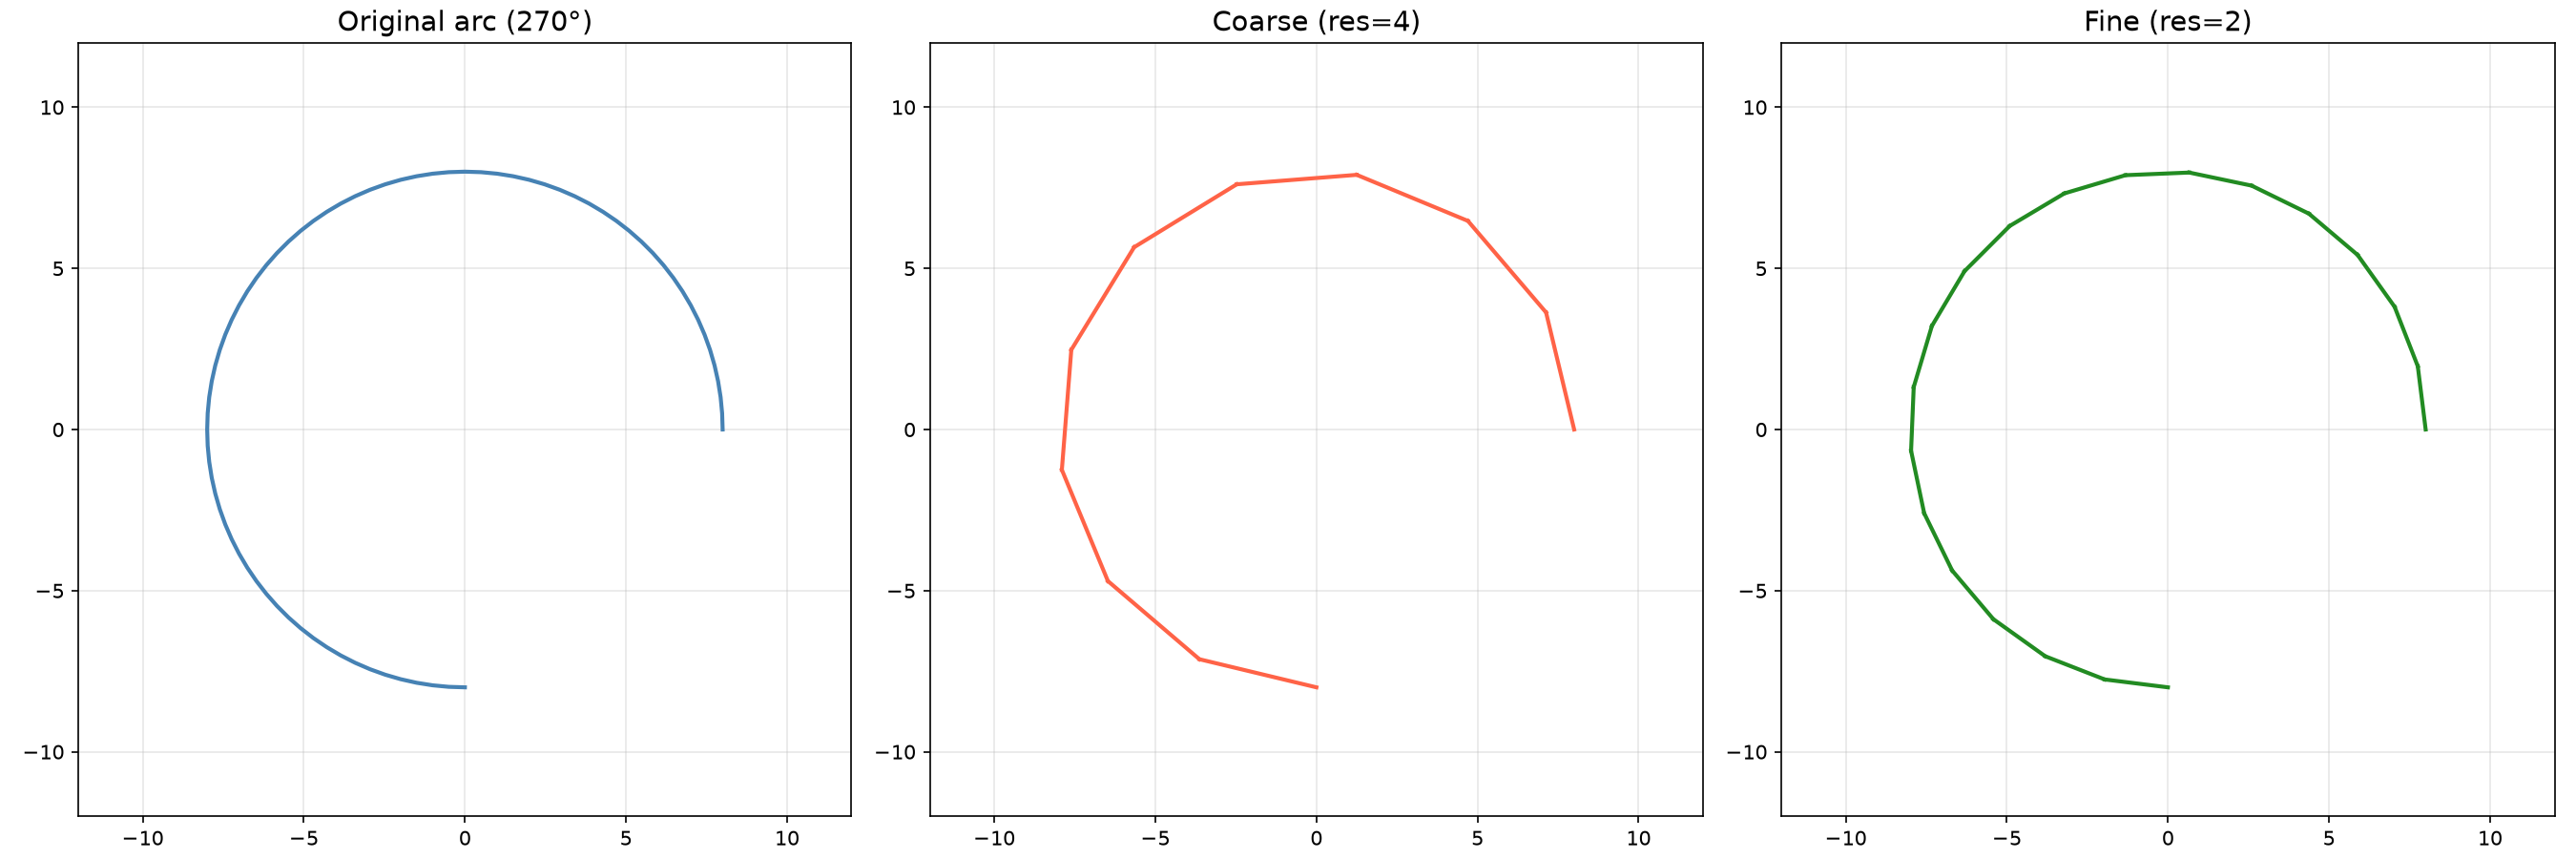
Arc linearization: coarse and fine resolution
normalize_angle()
normalize_angle(angle: float) -> float
Normalize an angle to the range [0, 2*pi).
| Parameter | Type | Description |
|---|---|---|
angle | float | Angle in radians. |
| Returns | float | Normalized angle in [0, 2*pi). |
| Complexity | O(1) time, O(1) space |
normalize_angle_signed()
normalize_angle_signed(angle: float) -> float
Normalize an angle to the range [-pi, pi).
| Parameter | Type | Description |
|---|---|---|
angle | float | Angle in radians. |
| Returns | float | Normalized angle in [-pi, pi). |
| Complexity | O(1) time, O(1) space |