


raygeo.geo.shape.point
Individual point operations.
Provides equality testing within a configurable tolerance, midpoint computation between two points, 2D/3D get_circumcenter of three points, applying a 4x4 affine transformation matrix to a single point, point interpolation along a sequence, and moving-average smoothing of point sequences.
Functions
are_points_equal_3d()
are_points_equal_3d(
    p1: types.Point3D,
    p2: types.Point3D,
    tolerance: float,
) -> bool
Check if two 3D points are equal within tolerance.
| Parameter | Type | Description |
|---|---|---|
p1 | types.Point3D | First point (x, y, z). |
p2 | types.Point3D | Second point (x, y, z). |
tolerance | float | Maximum allowed difference. |
| Returns | bool | True if points are equal within tolerance. |
| Complexity | O(1) time, O(1) space |
get_circumcenter()
get_circumcenter(
    a: types.Point,
    b: types.Point,
    c: types.Point,
) -> tuple[types.Point, float]
Compute the get_circumcenter and radius of three 2D points.
Returns the center of the unique circle passing through all three points along with its radius.
Returns ((0.0, 0.0), -1.0) when the points are collinear.
| Parameter | Type | Description |
|---|---|---|
a | types.Point | First point (x, y). |
b | types.Point | Second point (x, y). |
c | types.Point | Third point (x, y). |
| Returns | tuple[types.Point, float] | (center, radius) where center is (x, y). |
| Complexity | O(1) time, O(1) space |
get_circumcenter_3d()
get_circumcenter_3d(
    a: types.Point3D,
    b: types.Point3D,
    c: types.Point3D,
) -> Optional[types.Point3D]
Compute the get_circumcenter of three 3D points.
Returns the center of the unique circle passing through all three points. Returns None when the
points are collinear.
| Parameter | Type | Description |
|---|---|---|
a | types.Point3D | First point (x, y, z). |
b | types.Point3D | Second point (x, y, z). |
c | types.Point3D | Third point (x, y, z). |
| Returns | Optional[types.Point3D] | Circumcenter (x, y, z) or None if collinear. |
| Complexity | O(1) time, O(1) space |
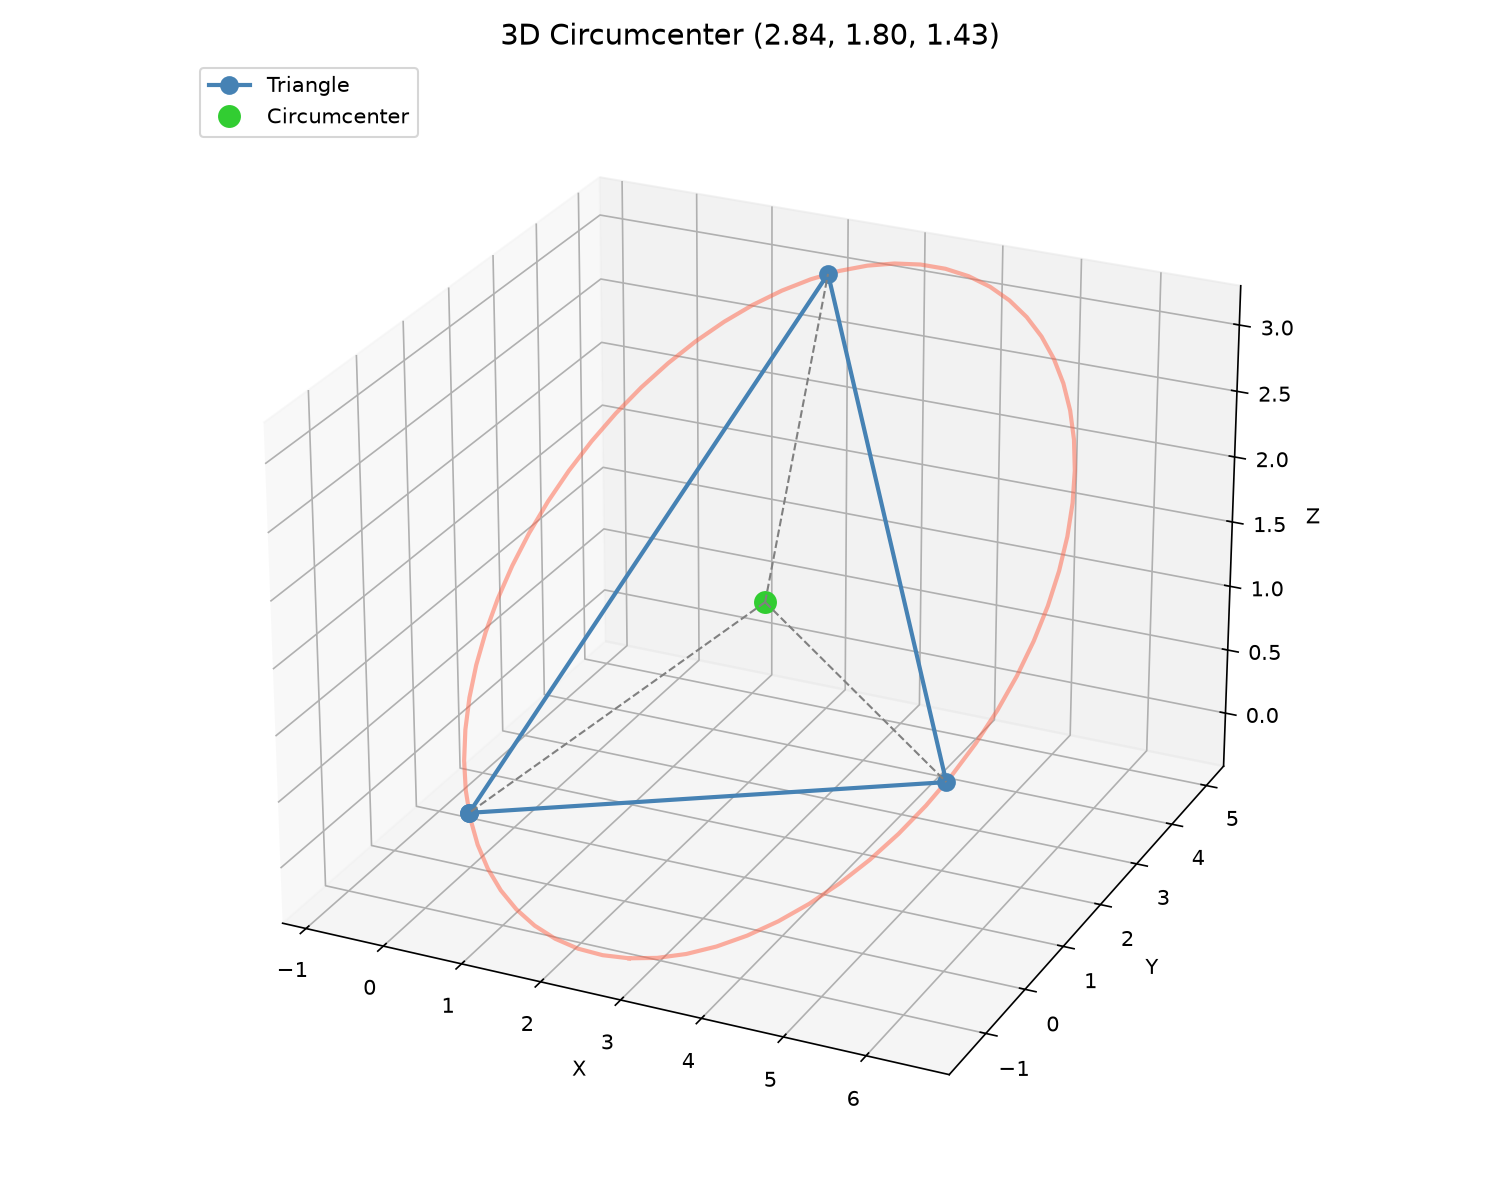
Circumcenter of three 3D points with circumcircle
get_midpoint_3d()
get_midpoint_3d(p1: types.Point3D, p2: types.Point3D) -> types.Point3D
Get the midpoint between two 3D points.
| Parameter | Type | Description |
|---|---|---|
p1 | types.Point3D | First point (x, y, z). |
p2 | types.Point3D | Second point (x, y, z). |
| Returns | types.Point3D | Midpoint (x, y, z). |
| Complexity | O(1) time, O(1) space |
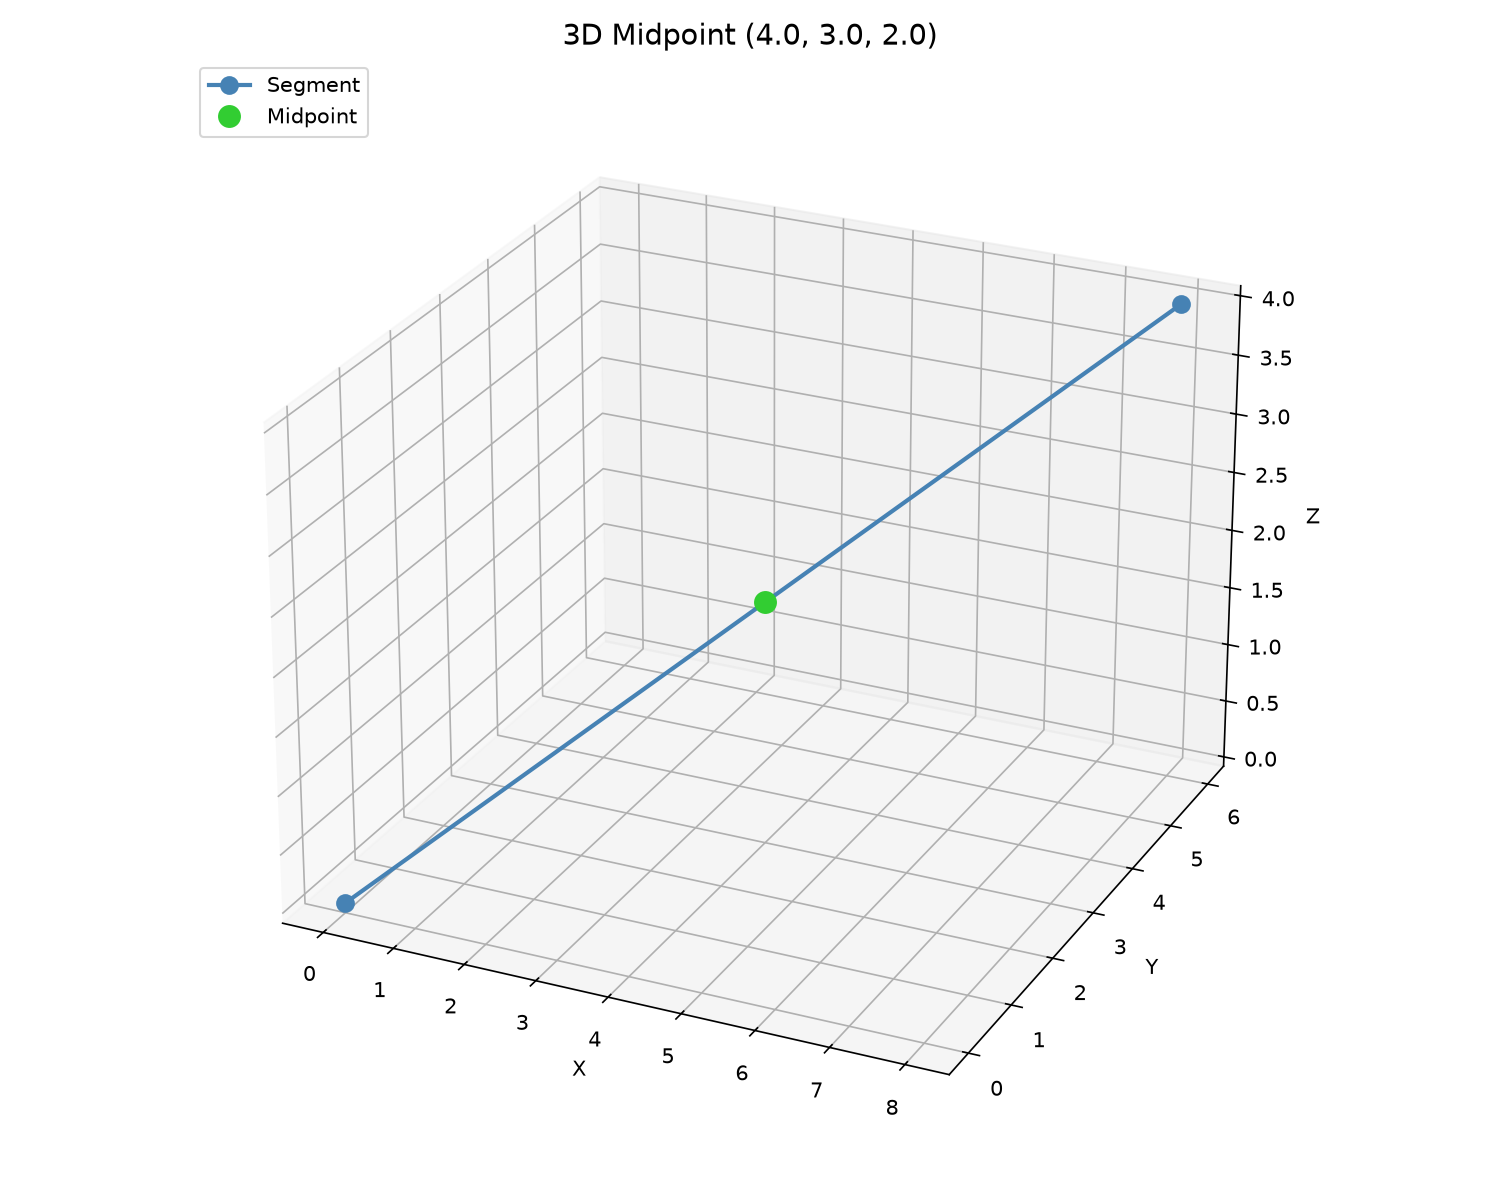
Midpoint of a 3D segment
get_point_at_fraction()
get_point_at_fraction(
    points: list[types.Point],
    fraction: float,
) -> types.Point
Get the point at a normalized fraction along a point sequence.
Linear interpolation along the polyline formed by points: fraction 0.0 is the first point, 1.0 is
the last point.
| Parameter | Type | Description |
|---|---|---|
points | list[types.Point] | Sequence of points (x, y). |
fraction | float | Normalized position along the sequence [0, 1]. |
| Returns | types.Point | Interpolated point (x, y). |
| Complexity | O(1) time, O(1) space |
get_points_moving_average()
get_points_moving_average(
    points: list[types.Point],
    radius: int,
) -> list[types.Point]
Apply a moving average to a point sequence.
Each output point is the mean of the input points within radius positions on either side; the
window shrinks and renormalizes near the sequence ends.
| Parameter | Type | Description |
|---|---|---|
points | list[types.Point] | Sequence of points (x, y). |
radius | int | Window radius in points. |
| Returns | list[types.Point] | Smoothed sequence of points (x, y). |
| Complexity | O(n * r) time, O(n) space where n is the point count and r the radius |
rotate_point()
rotate_point(point: types.Point, angle: float) -> types.Point
Rotate a 2D point around the origin.
| Parameter | Type | Description |
|---|---|---|
point | types.Point | Point (x, y) to rotate. |
angle | float | Rotation angle in radians (counter-clockwise). |
| Returns | types.Point | Rotated point (x, y). |
| Complexity | O(1) time, O(1) space |
transform_point_3d()
transform_point_3d(
    matrix: Sequence[Sequence[float]],
    x: float,
    y: float,
    z: float,
) -> types.Point3D
Apply an affine transformation matrix to a 3D point.
| Parameter | Type | Description |
|---|---|---|
matrix | Sequence[Sequence[float]] | 4x4 affine transformation matrix. |
x | float | X coordinate. |
y | float | Y coordinate. |
z | float | Z coordinate. |
| Returns | types.Point3D | Transformed point (x, y, z). |
| Complexity | O(1) time, O(1) space |