


raygeo.image.dither
Functions
apply_bayer_dither()
apply_bayer_dither(
    grayscale: numpy.NDArray[numpy.uint8],
    bayer_matrix: numpy.NDArray[numpy.float32],
    invert: bool,
    cell_size: int = 1,
) -> numpy.NDArray[numpy.uint8]
Apply ordered (Bayer) dithering using a threshold matrix.
| Parameter | Type | Description |
|---|---|---|
grayscale | numpy.NDArray[numpy.uint8] | 2D grayscale image as uint8 array. |
bayer_matrix | numpy.NDArray[numpy.float32] | 2D Bayer threshold matrix as float32. |
invert | bool | If True, invert the output. |
cell_size | int = 1 | Pixel grouping size for the threshold. |
| Returns | numpy.NDArray[numpy.uint8] | 2D binary uint8 array (values 0 or 1). |
| Complexity | O(w*h) |
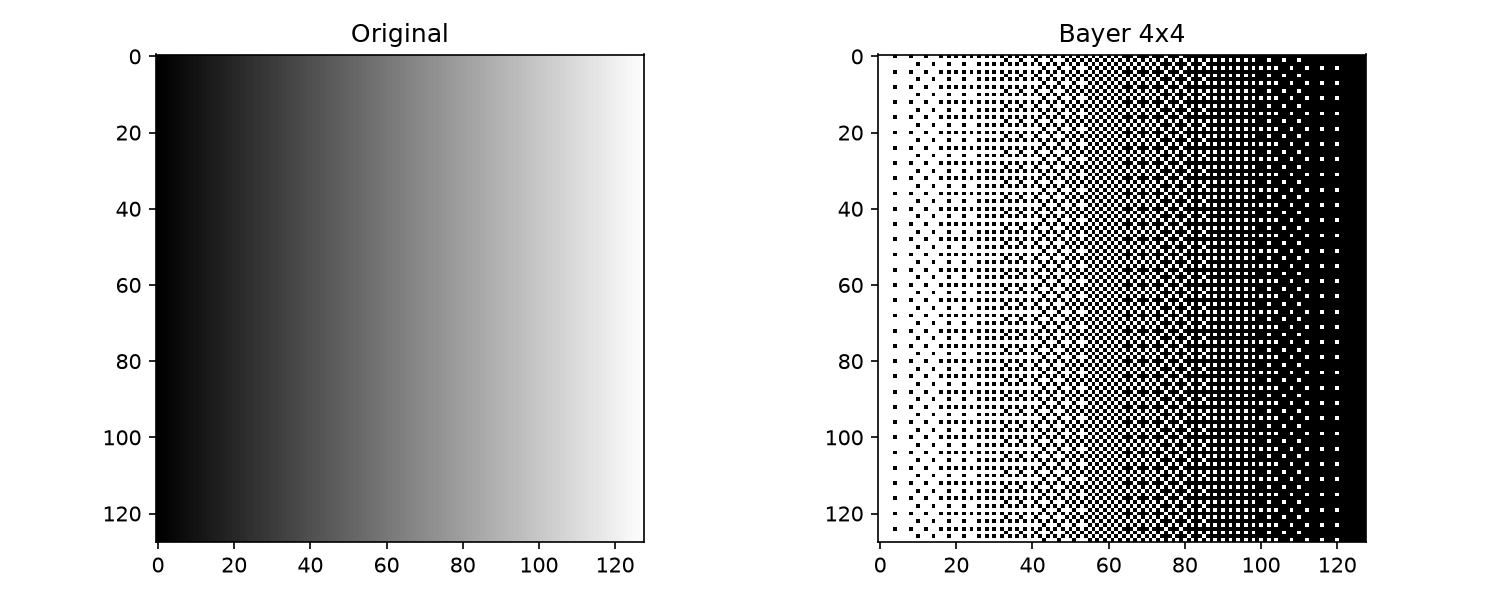
Bayer 4x4 ordered dithering
apply_error_diffusion_dither()
apply_error_diffusion_dither(
    grayscale: numpy.NDArray[numpy.uint8],
    kernel: str,
    invert: bool = False,
    serpentine: bool = False,
) -> numpy.NDArray[numpy.uint8]
Error-diffusion dithering with a named kernel.
Dithers in linear light. Available kernels: atkinson, burkes, floyd_steinberg, jarvis_judice_ninke, sierra, sierra_2row, sierra_lite, stucki.
Raises: ValueError — If the kernel name is not recognized.
| Parameter | Type | Description |
|---|---|---|
grayscale | numpy.NDArray[numpy.uint8] | 2D grayscale image as uint8 array. |
kernel | str | Name of the error-diffusion kernel to use. |
invert | bool = False | If True, invert the output (swap black/white). |
serpentine | bool = False | Scan odd rows right-to-left, mirroring the kernel. Avoids directional artifacts. |
| Returns | numpy.NDArray[numpy.uint8] | 2D binary uint8 array (values 0 or 1, 1 marks dark). |
| Complexity | O(w*h) |
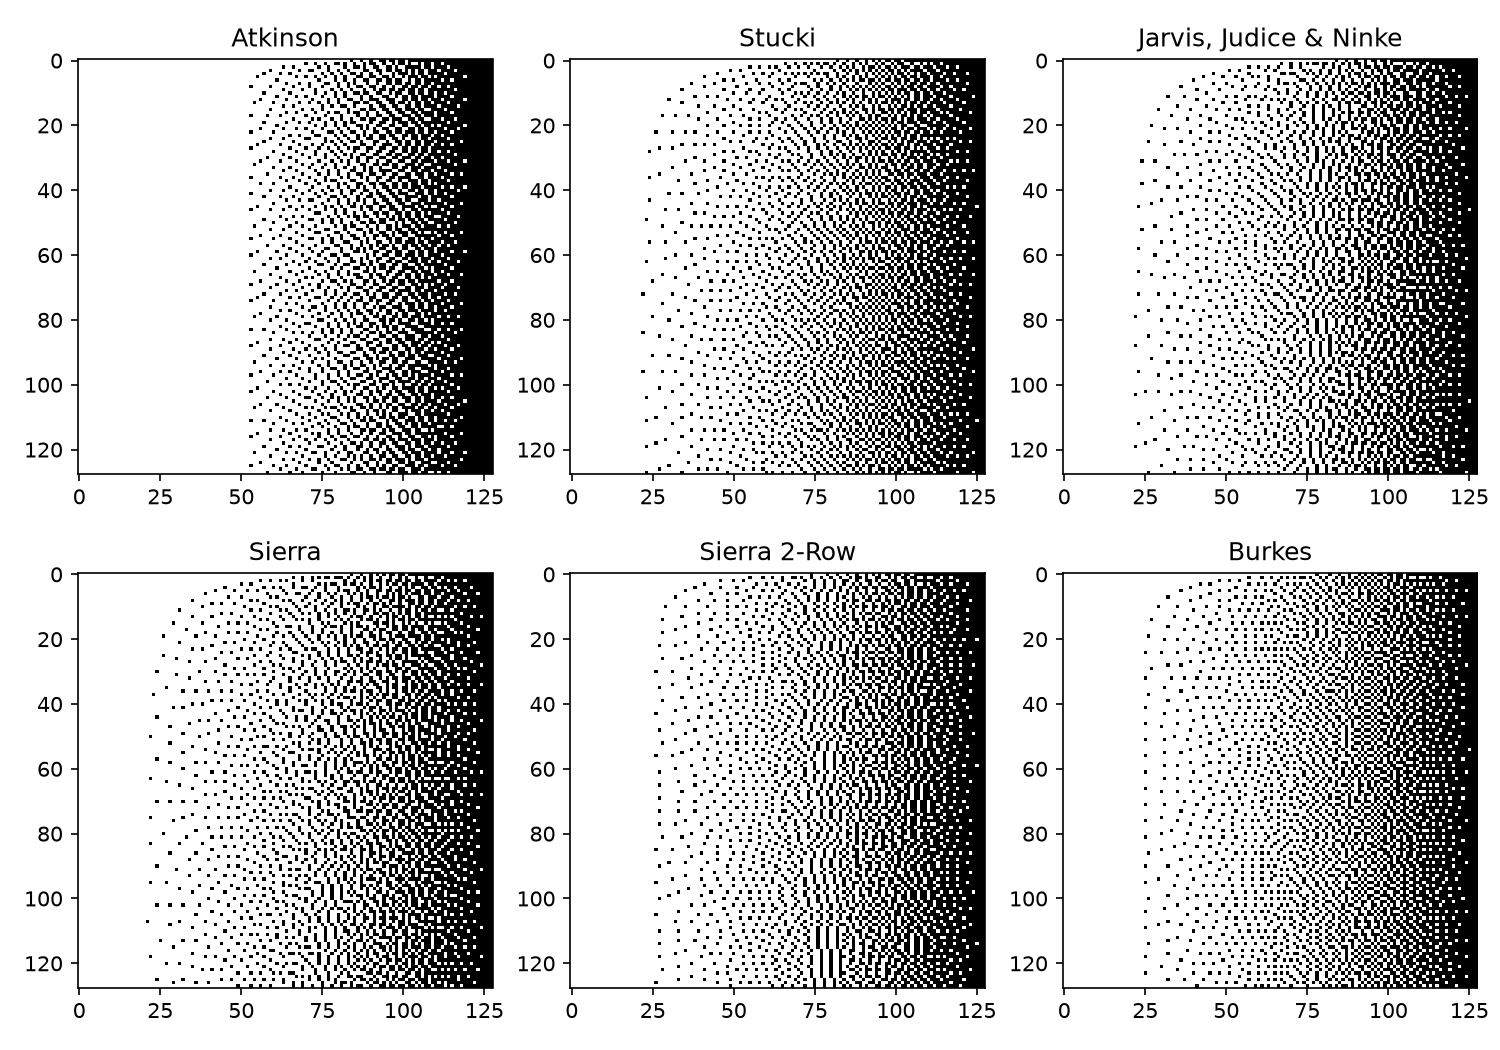
Error-diffusion kernel comparison
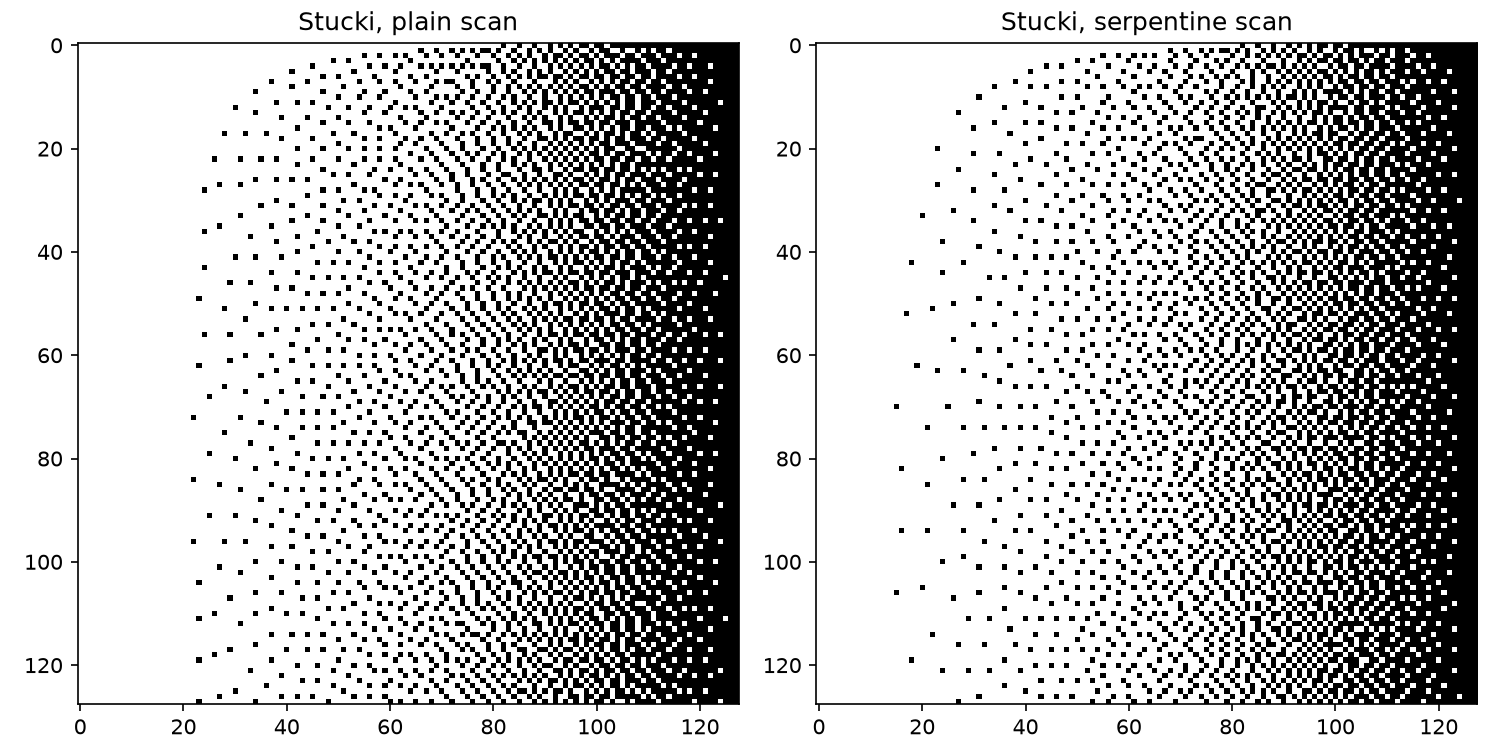
Stucki kernel with plain and serpentine scan
apply_floyd_steinberg_dither()
apply_floyd_steinberg_dither(
    grayscale: numpy.NDArray[numpy.uint8],
    invert: bool,
) -> numpy.NDArray[numpy.uint8]
Apply Floyd-Steinberg error-diffusion dithering.
| Parameter | Type | Description |
|---|---|---|
grayscale | numpy.NDArray[numpy.uint8] | 2D grayscale image as uint8 array. |
invert | bool | If True, invert the output (swap black/white). |
| Returns | numpy.NDArray[numpy.uint8] | 2D binary uint8 array (values 0 or 1). |
| Complexity | O(w*h) |
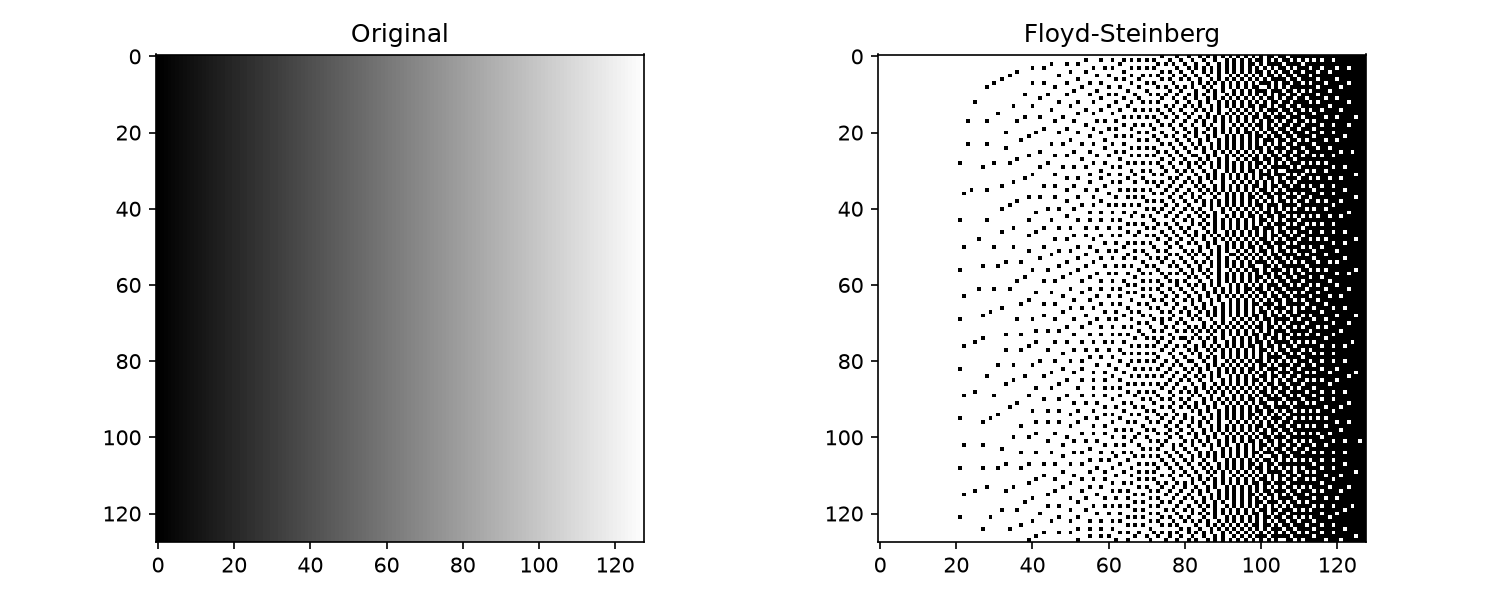
Floyd-Steinberg dithering
apply_halftone_dither()
apply_halftone_dither(
    grayscale: numpy.NDArray[numpy.uint8],
    cell_size_mm: float,
    angle_degrees: float,
    pixels_per_mm: tuple[float, float] = (1, 1),
    invert: bool = False,
) -> numpy.NDArray[numpy.uint8]
Amplitude-modulated halftone screen with round dots.
The screen is laid out in millimetres, so dots stay round on non-square pixels. Dot area tracks darkness: a pixel is set when its brightness is below the share of the cell that the spot function ranks at or under it.
Raises: ValueError — If pixels_per_mm is not positive.
| Parameter | Type | Description |
|---|---|---|
grayscale | numpy.NDArray[numpy.uint8] | 2D grayscale image as uint8 array. |
cell_size_mm | float | Distance between dot centres in mm. Non-positive values fall back to one-pixel cells. |
angle_degrees | float | Rotation of the dot grid in degrees. |
pixels_per_mm | tuple[float, float] = (1, 1) | (x, y) image resolution in pixels per mm. |
invert | bool = False | If True, invert the output (swap black/white). |
| Returns | numpy.NDArray[numpy.uint8] | 2D binary uint8 array (values 0 or 1, 1 marks dark). |
| Complexity | O(w*h) |
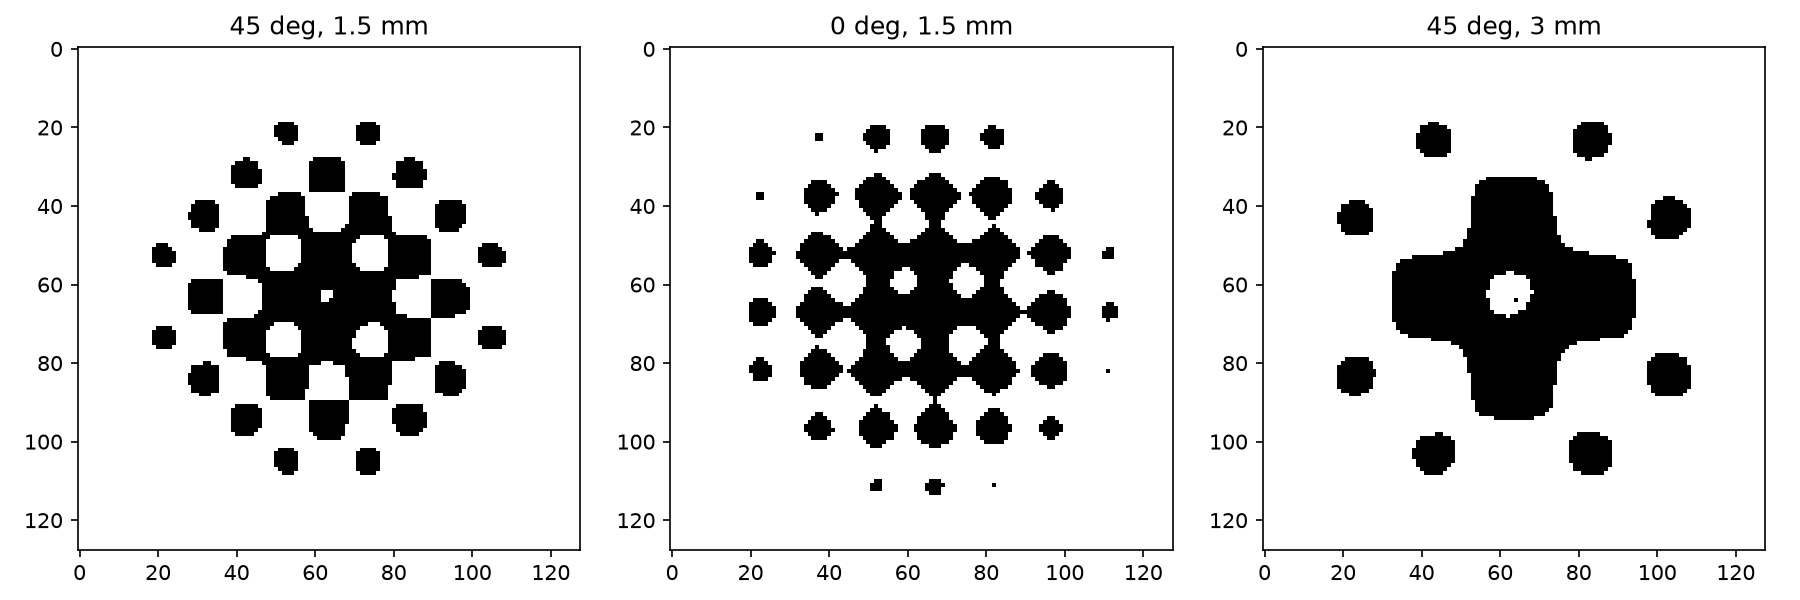
Halftone screens at different angles and cell sizes
apply_minimum_run_length()
apply_minimum_run_length(
    binary: numpy.NDArray[numpy.uint8],
    min_run_length: int,
) -> numpy.NDArray[numpy.uint8]
Remove binary runs shorter than the given minimum.
| Parameter | Type | Description |
|---|---|---|
binary | numpy.NDArray[numpy.uint8] | 2D binary uint8 array (values 0 or 1). |
min_run_length | int | Minimum run length to keep. |
| Returns | numpy.NDArray[numpy.uint8] | 2D binary uint8 array with short runs removed. |
| Complexity | O(w*h) |
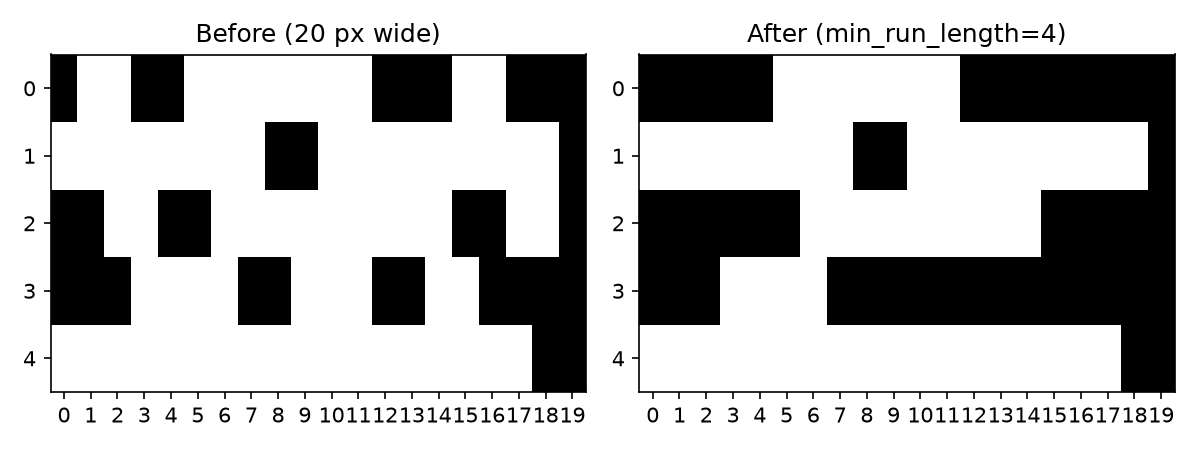
Minimum run length applied to binary image
apply_newsprint_dither()
apply_newsprint_dither(
    grayscale: numpy.NDArray[numpy.uint8],
    cell_size: int = 1,
    pixels_per_mm: tuple[float, float] = (1, 1),
    invert: bool = False,
) -> numpy.NDArray[numpy.uint8]
Clustered-dot ordered dithering (newsprint screen).
Tiles an 8x8 threshold matrix whose dots sit on a 45 degree lattice. Cells are kept square in millimetres using pixels_per_mm, so the screen does not stretch on non-square pixels.
Raises: ValueError — If pixels_per_mm is not positive.
| Parameter | Type | Description |
|---|---|---|
grayscale | numpy.NDArray[numpy.uint8] | 2D grayscale image as uint8 array. |
cell_size | int = 1 | Screen cell size in pixels. |
pixels_per_mm | tuple[float, float] = (1, 1) | (x, y) image resolution in pixels per mm. |
invert | bool = False | If True, invert the output (swap black/white). |
| Returns | numpy.NDArray[numpy.uint8] | 2D binary uint8 array (values 0 or 1, 1 marks dark). |
| Complexity | O(w*h) |
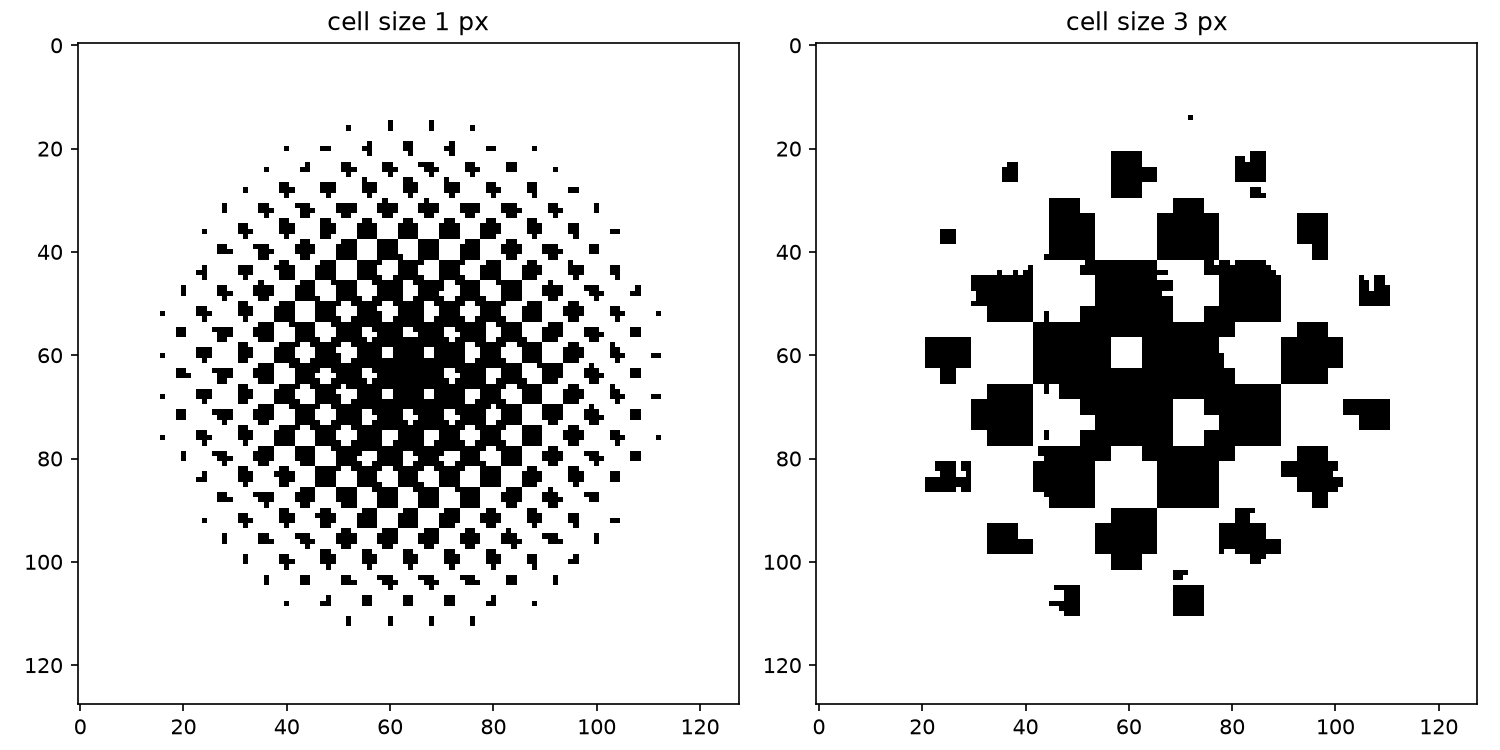
Newsprint clustered-dot screen at two cell sizes